
ABB ACS310
Pump and fan frequency converter with built-in PID and multi-pump control, over embedded Modbus RTU.
The ABB ACS310 is a frequency converter that controls the speed of pumps and fans in buildings and water systems, such as booster stations. This Modbus RTU template reads frequency, current, power, energy, PID values, faults and alarms, and lets you start, stop and set the speed, ramps, limits and PID setpoints from ModbusCloud.
- Protocol
- Modbus RTU
- Connection
- RS485, 9600 baud
- Registers
- 649, read and write
- Brand
- ABB
- Key readings
- Output frequency · Motor current · Motor power · DC bus voltage · Drive temperature · Energy counter · Last fault · PID feedback
- Available commands
- Control word · Speed reference · PID setpoint · Acceleration and deceleration time · Maximum frequency · Drive parameters
- Compatible models
- ACS310-01E · ACS310-01U · ACS310-03E · ACS310-03U
- Last updated
Registers (649)
639 read, 515 write
| Name | Unit | Access | Address (Hidden until you enter your email) | Function (hidden) | Type (hidden) |
|---|---|---|---|---|---|
| Control Word | Read and write | ||||
| Reference 1 | Read and write | ||||
| Reference 2 | Read and write | ||||
| Status Word | Read | ||||
| Actual Value 1 | Read | ||||
| Actual Value 2 | Read | ||||
| Actual Value 3 | Read | ||||
| Actual Value 4 | Read | ||||
| Actual Value 5 | Read | ||||
| Actual Value 6 | Read | ||||
| Actual Value 7 | Read | ||||
| Actual Value 8 | Read | ||||
| Modbus Data In 1 | Read | ||||
| Modbus Data In 2 | Read | ||||
| DCU Control Word LSW | Read and write | ||||
| DCU Control Word MSW | Read and write | ||||
| DCU Status Word LSW | Read | ||||
| DCU Status Word MSW | Read | ||||
| Modbus Data Out 1 | Write | ||||
| Modbus Data Out 2 | Write | ||||
| Modbus Data Out 3 | Write | ||||
| Modbus Data Out 4 | Write | ||||
| Modbus Data Out 5 | Write | ||||
| Modbus Data Out 6 | Write | ||||
| Modbus Data Out 7 | Write | ||||
| Modbus Data Out 8 | Write | ||||
| Modbus Data Out 9 | Write | ||||
| Modbus Data Out 10 | Write | ||||
| Speed & Dir | rpm | Read | |||
| Speed | rpm | Read | |||
| Output Freq | Hz | Read | |||
| Current | A | Read | |||
| Torque | % | Read | |||
| Power | kW | Read | |||
| DC Bus Voltage | V | Read | |||
| Output Voltage | V | Read | |||
| Drive Temp | °C | Read | |||
| External REF 1 | Hz | Read | |||
| External REF 2 | % | Read | |||
| Ctrl Location | Read | ||||
| Run Time (R) | h | Read | |||
| KWH Counter (R) | kWh | Read | |||
| Appl Blk Output | % | Read | |||
| AI 1 | % | Read | |||
| AI 2 | % | Read | |||
| AO 1 | mA | Read | |||
| PID 1 Output | % | Read | |||
| PID 2 Output | % | Read | |||
| PID 1 Setpnt | Read | ||||
| PID 2 Setpnt | Read | ||||
| PID 1 Fbk | Read | ||||
| PID 2 Fbk | Read | ||||
| PID 1 Deviation | Read | ||||
| PID 2 Deviation | Read | ||||
| COMM RO Word | Read | ||||
| COMM Value 1 | Read | ||||
| COMM Value 2 | Read | ||||
| Process Var 1 | Read | ||||
| Process Var 2 | Read | ||||
| Process Var 3 | Read | ||||
| Run Time | h | Read | |||
| MWH Counter | MWh | Read | |||
| Revolution Cntr | Read | ||||
| Drive On Time Hi | d | Read | |||
| Drive On Time Lo | s | Read | |||
| Motor Temp | Read | ||||
| PID COMM Value 1 | Read | ||||
| PID COMM Value 2 | Read | ||||
| DI 1-5 Status | Read | ||||
| Pulse Input Freq | Hz | Read | |||
| RO Status | Read | ||||
| TO Status | Read | ||||
| TO Frequency | Hz | Read | |||
| RO 2-4 Status | Read | ||||
| Saved KWH | kWh | Read | |||
| Saved MWH | MWh | Read | |||
| Saved Amount 1 | Read | ||||
| Saved Amount 2 | Read | ||||
| Saved CO2 | t | Read | |||
| FB CMD Word 1 | Read | ||||
| FB CMD Word 2 | Read | ||||
| FB STS Word 1 | Read | ||||
| FB STS Word 2 | Read | ||||
| Fault Word 1 | Read | ||||
| Fault Word 2 | Read | ||||
| Fault Word 3 | Read | ||||
| Alarm Word 1 | Read | ||||
| Alarm Word 2 | Read | ||||
| Alarm Word 3 | Read | ||||
| Last Fault | Read | ||||
| Fault Time 1 | d | Read | |||
| Fault Time 2 | Read | ||||
| Speed At Flt | rpm | Read | |||
| Freq At Flt | Hz | Read | |||
| Voltage At Flt | V | Read | |||
| Current At Flt | A | Read | |||
| Torque At Flt | % | Read | |||
| Status At Flt | Read | ||||
| Previous Fault 1 | Read | ||||
| Previous Fault 2 | Read | ||||
| DI 1-5 At Flt | Read | ||||
| EXT1 Commands | Read and write | ||||
| EXT2 Commands | Read and write | ||||
| Direction | Read and write | ||||
| Panel Force Stop | Read and write | ||||
| Keypad REF | Read and write | ||||
| EXT1/EXT2 Sel | Read and write | ||||
| REF1 Select | Read and write | ||||
| REF1 Min | Hz | Read and write | |||
| REF1 Max | Hz | Read and write | |||
| REF2 Select | Read and write | ||||
| REF2 Min | % | Read and write | |||
| REF2 Max | % | Read and write | |||
| Const Speed Sel | Read and write | ||||
| Const Speed 1 | Hz | Read and write | |||
| Const Speed 2 | Hz | Read and write | |||
| Const Speed 3 | Hz | Read and write | |||
| Const Speed 4 | Hz | Read and write | |||
| Const Speed 5 | Hz | Read and write | |||
| Const Speed 6 | Hz | Read and write | |||
| Const Speed 7 | Hz | Read and write | |||
| Timed Mode Sel | Read and write | ||||
| Minimum AI1 | % | Read and write | |||
| Maximum AI1 | % | Read and write | |||
| Filter AI1 | s | Read and write | |||
| Minimum AI2 | % | Read and write | |||
| Maximum AI2 | % | Read and write | |||
| Filter AI2 | s | Read and write | |||
| Relay Output 1 | Read and write | ||||
| Relay Output 2 | Read and write | ||||
| Relay Output 3 | Read and write | ||||
| RO 1 On Delay | s | Read and write | |||
| RO 1 Off Delay | s | Read and write | |||
| RO 2 On Delay | s | Read and write | |||
| RO 2 Off Delay | s | Read and write | |||
| RO 3 On Delay | s | Read and write | |||
| RO 3 Off Delay | s | Read and write | |||
| Relay Output 4 | Read and write | ||||
| RO 4 On Delay | s | Read and write | |||
| RO 4 Off Delay | s | Read and write | |||
| AO1 Content Sel | Read and write | ||||
| AO1 Content Min | Read and write | ||||
| AO1 Content Max | Read and write | ||||
| Minimum AO1 | mA | Read and write | |||
| Maximum AO1 | mA | Read and write | |||
| Filter AO1 | s | Read and write | |||
| Run Enable | Read and write | ||||
| Parameter Lock | Read and write | ||||
| Pass Code | Read and write | ||||
| Fault Reset Sel | Read and write | ||||
| User Par Set Chg | Read and write | ||||
| Local Lock | Read and write | ||||
| Param Save | Read and write | ||||
| Start Enable 1 | Read and write | ||||
| Start Enable 2 | Read and write | ||||
| Display Alarms | Read and write | ||||
| Parameter View | Read and write | ||||
| Fan Control | Read and write | ||||
| Freq Input Min | Hz | Read and write | |||
| Freq Input Max | Hz | Read and write | |||
| Filter Freq In | s | Read and write | |||
| TO Mode | Read and write | ||||
| DO Signal | Read and write | ||||
| DO On Delay | s | Read and write | |||
| DO Off Delay | s | Read and write | |||
| FO Content Sel | Read and write | ||||
| FO Content Min | Read and write | ||||
| FO Content Max | Read and write | ||||
| Minimum FO | Hz | Read and write | |||
| Maximum FO | Hz | Read and write | |||
| Filter FO | s | Read and write | |||
| DI1 On Delay | s | Read and write | |||
| DI1 Off Delay | s | Read and write | |||
| DI2 On Delay | s | Read and write | |||
| DI2 Off Delay | s | Read and write | |||
| DI3 On Delay | s | Read and write | |||
| DI3 Off Delay | s | Read and write | |||
| DI4 On Delay | s | Read and write | |||
| DI4 Off Delay | s | Read and write | |||
| DI5 On Delay | s | Read and write | |||
| DI5 Off Delay | s | Read and write | |||
| Max Current | A | Read and write | |||
| Overvolt Ctrl | Read and write | ||||
| Undervolt Ctrl | Read and write | ||||
| Minimum Freq | Hz | Read and write | |||
| Maximum Freq | Hz | Read and write | |||
| Start Function | Read and write | ||||
| Stop Function | Read and write | ||||
| DC Magn Time | s | Read and write | |||
| DC Hold Ctl | Read and write | ||||
| DC Curr REF | % | Read and write | |||
| DC Brake Time | s | Read and write | |||
| Start Inhibit | Read and write | ||||
| Emerg Stop Sel | Read and write | ||||
| Torq Boost Curr | % | Read and write | |||
| Zero Speed Delay | s | Read and write | |||
| Start Delay | s | Read and write | |||
| Heating | % | Read and write | |||
| Acc/Dec 1/2 Sel | Read and write | ||||
| Acceler Time 1 | s | Read and write | |||
| Deceler Time 1 | s | Read and write | |||
| Ramp Shape 1 | s | Read and write | |||
| Acceler Time 2 | s | Read and write | |||
| Deceler Time 2 | s | Read and write | |||
| Ramp Shape 2 | s | Read and write | |||
| Emerg Dec Time | s | Read and write | |||
| Ramp Input 0 | Read and write | ||||
| Crit Speed Sel | Read and write | ||||
| Crit Speed 1 Lo | Hz | Read and write | |||
| Crit Speed 1 Hi | Hz | Read and write | |||
| Crit Speed 2 Lo | Hz | Read and write | |||
| Crit Speed 2 Hi | Hz | Read and write | |||
| Crit Speed 3 Lo | Hz | Read and write | |||
| Crit Speed 3 Hi | Hz | Read and write | |||
| IR Comp Volt | V | Read and write | |||
| IR Comp Freq | % | Read and write | |||
| U/F Ratio | Read and write | ||||
| Switching Freq | Read and write | ||||
| Switch Freq Ctrl | Read and write | ||||
| Slip Comp Ratio | % | Read and write | |||
| Noise Smoothing | Read and write | ||||
| User Defined U1 | V | Read and write | |||
| User Defined F1 | Hz | Read and write | |||
| User Defined U2 | V | Read and write | |||
| User Defined F2 | Hz | Read and write | |||
| User Defined U3 | V | Read and write | |||
| User Defined F3 | Hz | Read and write | |||
| User Defined U4 | V | Read and write | |||
| User Defined F4 | Hz | Read and write | |||
| FW Voltage | V | Read and write | |||
| DC Stabilizer | Read and write | ||||
| Cooling Fan Trig | h | Read and write | |||
| Cooling Fan ACT | h | Read and write | |||
| Revolution Trig | Read and write | ||||
| Revolution ACT | Read and write | ||||
| Run Time Trig | h | Read and write | |||
| Run Time ACT | h | Read and write | |||
| Ai<Min Function | Read and write | ||||
| Panel COMM Err | Read and write | ||||
| External Fault 1 | Read and write | ||||
| External Fault 2 | Read and write | ||||
| Mot Therm Prot | Read and write | ||||
| Mot Therm Time | s | Read and write | |||
| Mot Load Curve | % | Read and write | |||
| Zero Speed Load | % | Read and write | |||
| Break Point Freq | Hz | Read and write | |||
| Stall Function | Read and write | ||||
| Stall Frequency | Hz | Read and write | |||
| Stall Time | s | Read and write | |||
| Supply Phase | Read and write | ||||
| Earth Fault | Read and write | ||||
| COMM Fault Func | Read and write | ||||
| COMM Fault Time | s | Read and write | |||
| AI1 Fault Limit | % | Read and write | |||
| AI2 Fault Limit | % | Read and write | |||
| Wiring Fault | Read and write | ||||
| Option Com Loss | Read and write | ||||
| Nr Of Trials | Read and write | ||||
| Trial Time | s | Read and write | |||
| Delay Time | s | Read and write | |||
| AR Overcurrent | Read and write | ||||
| AR Overvoltage | Read and write | ||||
| AR Undervoltage | Read and write | ||||
| AR Ai<Min | Read and write | ||||
| AR External Flt | Read and write | ||||
| Superv 1 Param | Read and write | ||||
| Superv 1 Lim Lo | Read and write | ||||
| Superv 1 Lim Hi | Read and write | ||||
| Superv 2 Param | Read and write | ||||
| Superv 2 Lim Lo | Read and write | ||||
| Superv 2 Lim Hi | Read and write | ||||
| Superv 3 Param | Read and write | ||||
| Superv 3 Lim Lo | Read and write | ||||
| Superv 3 Lim Hi | Read and write | ||||
| Firmware | Read | ||||
| Loading Package | Read | ||||
| Test Date | Read | ||||
| Drive Rating | Read | ||||
| Parameter Table | Read | ||||
| SIGNAL1 Param | Read and write | ||||
| SIGNAL1 Min | Read and write | ||||
| SIGNAL1 Max | Read and write | ||||
| OUTPUT1 Dsp Form | Read and write | ||||
| OUTPUT1 Unit | Read and write | ||||
| OUTPUT1 Min | Read and write | ||||
| OUTPUT1 Max | Read and write | ||||
| SIGNAL2 Param | Read and write | ||||
| SIGNAL2 Min | Read and write | ||||
| SIGNAL2 Max | Read and write | ||||
| OUTPUT2 Dsp Form | Read and write | ||||
| OUTPUT2 Unit | Read and write | ||||
| OUTPUT2 Min | Read and write | ||||
| OUTPUT2 Max | Read and write | ||||
| SIGNAL3 Param | Read and write | ||||
| SIGNAL3 Min | Read and write | ||||
| SIGNAL3 Max | Read and write | ||||
| OUTPUT3 Dsp Form | Read and write | ||||
| OUTPUT3 Unit | Read and write | ||||
| OUTPUT3 Min | Read and write | ||||
| OUTPUT3 Max | Read and write | ||||
| Sensor Type | Read and write | ||||
| Input Selection | Read and write | ||||
| Alarm Limit | Read and write | ||||
| Fault Limit | Read and write | ||||
| AO Excitation | Read and write | ||||
| Timers Enable | Read and write | ||||
| Start Time 1 | Read and write | ||||
| Stop Time 1 | Read and write | ||||
| Start Day 1 | Read and write | ||||
| Stop Day 1 | Read and write | ||||
| Start Time 2 | Read and write | ||||
| Stop Time 2 | Read and write | ||||
| Start Day 2 | Read and write | ||||
| Stop Day 2 | Read and write | ||||
| Start Time 3 | Read and write | ||||
| Stop Time 3 | Read and write | ||||
| Start Day 3 | Read and write | ||||
| Stop Day 3 | Read and write | ||||
| Start Time 4 | Read and write | ||||
| Stop Time 4 | Read and write | ||||
| Start Day 4 | Read and write | ||||
| Stop Day 4 | Read and write | ||||
| Booster Sel | Read and write | ||||
| Booster Time | Read and write | ||||
| Timed Func 1 Src | Read and write | ||||
| Timed Func 2 Src | Read and write | ||||
| Timed Func 3 Src | Read and write | ||||
| Timed Func 4 Src | Read and write | ||||
| Alternating Timer | Read and write | ||||
| User Load C Mode | Read and write | ||||
| User Load C Func | Read and write | ||||
| User Load C Time | s | Read and write | |||
| Load Freq 1 | Hz | Read and write | |||
| Load Torq Low 1 | % | Read and write | |||
| Load Torq High 1 | % | Read and write | |||
| Load Freq 2 | Hz | Read and write | |||
| Load Torq Low 2 | % | Read and write | |||
| Load Torq High 2 | % | Read and write | |||
| Load Freq 3 | Hz | Read and write | |||
| Load Torq Low 3 | % | Read and write | |||
| Load Torq High 3 | % | Read and write | |||
| Load Freq 4 | Hz | Read and write | |||
| Load Torq Low 4 | % | Read and write | |||
| Load Torq High 4 | % | Read and write | |||
| Load Freq 5 | Hz | Read and write | |||
| Load Torq Low 5 | % | Read and write | |||
| Load Torq High 5 | % | Read and write | |||
| PID1 Gain | Read and write | ||||
| PID1 Integration Time | s | Read and write | |||
| PID1 Derivation Time | s | Read and write | |||
| PID1 PID Deriv Filter | s | Read and write | |||
| PID1 Error Value Inv | Read and write | ||||
| PID1 Units | Read and write | ||||
| PID1 Unit Scale | Read and write | ||||
| PID1 0% Value | Read and write | ||||
| PID1 100% Value | Read and write | ||||
| PID1 Set Point Sel | Read and write | ||||
| PID1 Internal Setpnt | Read and write | ||||
| PID1 Setpoint Min | % | Read and write | |||
| PID1 Setpoint Max | % | Read and write | |||
| PID1 Fbk Sel | Read and write | ||||
| PID1 Fbk Multiplier | Read and write | ||||
| PID1 ACT1 Input | Read and write | ||||
| PID1 ACT2 Input | Read and write | ||||
| PID1 ACT1 Minimum | % | Read and write | |||
| PID1 ACT1 Maximum | % | Read and write | |||
| PID1 ACT2 Minimum | % | Read and write | |||
| PID1 ACT2 Maximum | % | Read and write | |||
| PID1 Sleep Selection | Read and write | ||||
| PID1 PID Sleep Level | Hz | Read and write | |||
| PID1 PID Sleep Delay | s | Read and write | |||
| PID1 Wake-Up Dev | Read and write | ||||
| PID1 Wake-Up Delay | s | Read and write | |||
| PID 1 Param Set | Read and write | ||||
| PID1 PID Out Min | % | Read and write | |||
| PID1 PID Out Max | % | Read and write | |||
| PID1 Sleep Boost Time | Read and write | ||||
| PID1 Sleep Boost Step | s | Read and write | |||
| PID REF Acc Time | s | Read and write | |||
| PID REF Dec Time | s | Read and write | |||
| PID REF Freeze | Read and write | ||||
| PID Out Freeze | Read and write | ||||
| PID1 Internal SETPNT2 | Read and write | ||||
| PID1 Internal SETPNT3 | Read and write | ||||
| PID1 Internal SETPNT4 | Read and write | ||||
| PID1 Int Setpnt Sel | Read and write | ||||
| PID2 Gain | Read and write | ||||
| PID2 Integration Time | s | Read and write | |||
| PID2 Derivation Time | s | Read and write | |||
| PID2 PID Deriv Filter | s | Read and write | |||
| PID2 Error Value Inv | Read and write | ||||
| PID2 Units | Read and write | ||||
| PID2 Unit Scale | Read and write | ||||
| PID2 0% Value | Read and write | ||||
| PID2 100% Value | Read and write | ||||
| PID2 Set Point Sel | Read and write | ||||
| PID2 Internal Setpnt | Read and write | ||||
| PID2 Setpoint Min | % | Read and write | |||
| PID2 Setpoint Max | % | Read and write | |||
| PID2 Fbk Sel | Read and write | ||||
| PID2 Fbk Multiplier | Read and write | ||||
| PID2 ACT1 Input | Read and write | ||||
| PID2 ACT2 Input | Read and write | ||||
| PID2 ACT1 Minimum | % | Read and write | |||
| PID2 ACT1 Maximum | % | Read and write | |||
| PID2 ACT2 Minimum | % | Read and write | |||
| PID2 ACT2 Maximum | % | Read and write | |||
| PID2 Sleep Selection | Read and write | ||||
| PID2 PID Sleep Level | Hz | Read and write | |||
| PID2 PID Sleep Delay | s | Read and write | |||
| PID2 Wake-Up Dev | Read and write | ||||
| PID2 Wake-Up Delay | s | Read and write | |||
| PID2 PID Out Min | % | Read and write | |||
| PID2 PID Out Max | % | Read and write | |||
| PID2 Sleep Boost Time | Read and write | ||||
| PID2 Sleep Boost Step | s | Read and write | |||
| PID2 Internal SETPNT2 | Read and write | ||||
| PID2 Internal SETPNT3 | Read and write | ||||
| PID2 Internal SETPNT4 | Read and write | ||||
| PID2 Int Setpnt Sel | Read and write | ||||
| Ext PID Gain | Read and write | ||||
| Ext PID Integration Time | s | Read and write | |||
| Ext PID Derivation Time | s | Read and write | |||
| Ext PID PID Deriv Filter | s | Read and write | |||
| Ext PID Error Value Inv | Read and write | ||||
| Ext PID Units | Read and write | ||||
| Ext PID Unit Scale | Read and write | ||||
| Ext PID 0% Value | Read and write | ||||
| Ext PID 100% Value | Read and write | ||||
| Ext PID Set Point Sel | Read and write | ||||
| Ext PID Internal Setpnt | Read and write | ||||
| Ext PID Setpoint Min | % | Read and write | |||
| Ext PID Setpoint Max | % | Read and write | |||
| Ext PID Fbk Sel | Read and write | ||||
| Ext PID Fbk Multiplier | Read and write | ||||
| Ext PID ACT1 Input | Read and write | ||||
| Ext PID ACT2 Input | Read and write | ||||
| Ext PID ACT1 Minimum | % | Read and write | |||
| Ext PID ACT1 Maximum | % | Read and write | |||
| Ext PID ACT2 Minimum | % | Read and write | |||
| Ext PID ACT2 Maximum | % | Read and write | |||
| Activate | Read and write | ||||
| Offset | % | Read and write | |||
| Trim Mode | Read and write | ||||
| Trim Scale | % | Read and write | |||
| Correction Src | Read and write | ||||
| Inlet Prot Ctrl | Read and write | ||||
| AI Measure Inlet | Read and write | ||||
| AI In Low Level | % | Read and write | |||
| Very Low Ctrl | Read and write | ||||
| AI In Very Low | % | Read and write | |||
| DI Status Inlet | Read and write | ||||
| Inlet Ctrl Dly | s | Read and write | |||
| Inlet Forced REF | % | Read and write | |||
| Outlet Prot Ctrl | Read and write | ||||
| AI Meas Outlet | Read and write | ||||
| AI Out Hi Level | % | Read and write | |||
| Very High Ctrl | Read and write | ||||
| AI Out Very High | % | Read and write | |||
| DI Status Outlet | Read and write | ||||
| Outlet Ctrl Dly | s | Read and write | |||
| Outlet Forced REF | % | Read and write | |||
| PID Out Dec Time | s | Read and write | |||
| Appl Profile Ctl | Read and write | ||||
| Profile Outp Lim | % | Read and write | |||
| Prof Limit On Dly | h | Read and write | |||
| Pipefill Enable | Read and write | ||||
| Pipefill Step | % | Read and write | |||
| Req ACT Change | % | Read and write | |||
| ACT Change Delay | s | Read and write | |||
| PID Enable Dev | % | Read and write | |||
| Pipefill Timeout | s | Read and write | |||
| Energy Optimizer | Read and write | ||||
| Energy Price | Read and write | ||||
| CO2 Conv Factor | Read and write | ||||
| Pump Power | % | Read and write | |||
| Energy Reset | Read and write | ||||
| Pump Clean Trig | Read and write | ||||
| Fwd Step | % | Read and write | |||
| Rev Step | % | Read and write | |||
| Off Time | s | Read and write | |||
| Fwd Time | s | Read and write | |||
| Rev Time | s | Read and write | |||
| Trig Time | h | Read and write | |||
| Count | Read and write | ||||
| Station ID | Read and write | ||||
| Baud Rate | Read and write | ||||
| Parity | Read and write | ||||
| Ok Messages | Read and write | ||||
| Parity Errors | Read and write | ||||
| Frame Errors | Read and write | ||||
| Buffer Overruns | Read and write | ||||
| CRC Errors | Read and write | ||||
| EFB Protocol ID | Read and write | ||||
| EFB Station ID | Read and write | ||||
| EFB Baud Rate | Read and write | ||||
| EFB Parity | Read and write | ||||
| EFB Ctrl Profile | Read and write | ||||
| EFB Ok Messages | Read and write | ||||
| EFB CRC Errors | Read and write | ||||
| EFB Uart Errors | Read and write | ||||
| EFB Status | Read and write | ||||
| EFB Par 10 | Read and write | ||||
| EFB Par 11 | Read and write | ||||
| EFB Par 12 | Read and write | ||||
| EFB Par 13 | Read and write | ||||
| EFB Par 14 | Read and write | ||||
| EFB Par 15 | Read and write | ||||
| EFB Par 16 | Read and write | ||||
| EFB Par 17 | Read and write | ||||
| EFB Par 18 | Read and write | ||||
| EFB Par 19 | Read | ||||
| EFB Par 20 | Read | ||||
| MDB Data In 1 | Read | ||||
| MDB Data In 2 | Read | ||||
| MDB Data Out 1 | Read and write | ||||
| MDB Data Out 2 | Read and write | ||||
| MDB Data Out 3 | Read and write | ||||
| MDB Data Out 4 | Read and write | ||||
| MDB Data Out 5 | Read and write | ||||
| MDB Data Out 6 | Read and write | ||||
| MDB Data Out 7 | Read and write | ||||
| MDB Data Out 8 | Read and write | ||||
| MDB Data Out 9 | Read and write | ||||
| MDB Data Out 10 | Read and write | ||||
| PVL Signal | Read and write | ||||
| PVL Filter Time | s | Read and write | |||
| Loggers Reset | Read and write | ||||
| AL2 Signal | Read and write | ||||
| AL2 Signal Base | Read and write | ||||
| Peak Value | Read and write | ||||
| Peak Time 1 | Read and write | ||||
| Peak Time 2 | s | Read and write | |||
| Current At Peak | A | Read and write | |||
| UDC At Peak | V | Read and write | |||
| Freq At Peak | Hz | Read and write | |||
| Time Of Reset 1 | Read and write | ||||
| Time Of Reset 2 | s | Read and write | |||
| AL1RANGE0TO10 | % | Read and write | |||
| AL1RANGE10TO20 | % | Read and write | |||
| AL1RANGE20TO30 | % | Read and write | |||
| AL1RANGE30TO40 | % | Read and write | |||
| AL1RANGE40TO50 | % | Read and write | |||
| AL1RANGE50TO60 | % | Read and write | |||
| AL1RANGE60TO70 | % | Read and write | |||
| AL1RANGE70TO80 | % | Read and write | |||
| AL1RANGE80TO90 | % | Read and write | |||
| AL1RANGE90TO | % | Read and write | |||
| AL2RANGE0TO10 | % | Read and write | |||
| AL2RANGE10TO20 | % | Read and write | |||
| AL2RANGE20TO30 | % | Read and write | |||
| AL2RANGE30TO40 | % | Read and write | |||
| AL2RANGE40TO50 | % | Read and write | |||
| AL2RANGE50TO60 | % | Read and write | |||
| AL2RANGE60TO70 | % | Read and write | |||
| AL2RANGE70TO80 | % | Read and write | |||
| AL2RANGE80TO90 | % | Read and write | |||
| AL2RANGE90TO | % | Read and write | |||
| Reference Step 1 | % | Read and write | |||
| Reference Step 2 | % | Read and write | |||
| Reference Step 3 | % | Read and write | |||
| Start Freq 1 | Hz | Read and write | |||
| Start Freq 2 | Hz | Read and write | |||
| Start Freq 3 | Hz | Read and write | |||
| Low Freq 1 | Hz | Read and write | |||
| Low Freq 2 | Hz | Read and write | |||
| Low Freq 3 | Hz | Read and write | |||
| Aux Mot Start D | s | Read and write | |||
| Aux Mot Stop D | s | Read and write | |||
| Nr Of Aux Mot | Read and write | ||||
| Autochng Interv | h | Read and write | |||
| Autochng Level | % | Read and write | |||
| Interlocks | Read and write | ||||
| Reg Bypass Ctrl | Read and write | ||||
| PFC Start Delay | s | Read and write | |||
| PFC Enable | Read and write | ||||
| Acc In Aux Stop | s | Read and write | |||
| Dec In Aux Start | s | Read and write | |||
| Timed Autochng | Read and write | ||||
| Motors | Read and write | ||||
| Aux Start Order | Read and write | ||||
| COMM Prot Sel | Read and write | ||||
| Language | Read and write | ||||
| Applic Macro | Read and write | ||||
| Motor Nom Volt | V | Read and write | |||
| Motor Nom Curr | A | Read and write | |||
| Motor Nom Freq | Hz | Read and write | |||
| Motor Nom Speed | rpm | Read and write | |||
| Motor Nom Power | kW | Read and write | |||
| Phase Inversion | Read and write | ||||
| Control Word Bit 0 | Read and write | ||||
| Control Word Bit 1 | Read and write | ||||
| Control Word Bit 2 | Read and write | ||||
| Control Word Bit 3 | Read and write | ||||
| Control Word Bit 4 | Read and write | ||||
| Control Word Bit 5 | Read and write | ||||
| Control Word Bit 6 | Read and write | ||||
| Control Word Bit 7 | Read and write | ||||
| Control Word Bit 8 | Read and write | ||||
| Control Word Bit 9 | Read and write | ||||
| Control Word Bit 10 | Read and write | ||||
| Control Word Bit 11 | Read and write | ||||
| Control Word Bit 12 | Read and write | ||||
| Control Word Bit 13 | Read and write | ||||
| Control Word Bit 14 | Read and write | ||||
| Control Word Bit 15 | Read and write | ||||
| Relay Output 1 State | Read and write | ||||
| Relay Output 2 State | Read and write | ||||
| Relay Output 3 State | Read and write | ||||
| Relay Output 4 State | Read and write | ||||
| Status Word Bit 0 | Read | ||||
| Status Word Bit 1 | Read | ||||
| Status Word Bit 2 | Read | ||||
| Status Word Bit 3 | Read | ||||
| Status Word Bit 4 | Read | ||||
| Status Word Bit 5 | Read | ||||
| Status Word Bit 6 | Read | ||||
| Status Word Bit 7 | Read | ||||
| Status Word Bit 8 | Read | ||||
| Status Word Bit 9 | Read | ||||
| Status Word Bit 10 | Read | ||||
| Status Word Bit 11 | Read | ||||
| Status Word Bit 12 | Read | ||||
| Status Word Bit 13 | Read | ||||
| Status Word Bit 14 | Read | ||||
| Status Word Bit 15 | Read | ||||
| Status Word Bit 16 | Read | ||||
| Status Word Bit 17 | Read | ||||
| Status Word Bit 18 | Read | ||||
| Status Word Bit 19 | Read | ||||
| Status Word Bit 20 | Read | ||||
| Status Word Bit 21 | Read | ||||
| Status Word Bit 22 | Read | ||||
| Status Word Bit 23 | Read | ||||
| Status Word Bit 24 | Read | ||||
| Status Word Bit 25 | Read | ||||
| Status Word Bit 26 | Read | ||||
| Status Word Bit 27 | Read | ||||
| Status Word Bit 28 | Read | ||||
| Status Word Bit 29 | Read | ||||
| Status Word Bit 30 | Read | ||||
| Status Word Bit 31 | Read | ||||
| Digital Input DI1 | Read | ||||
| Digital Input DI2 | Read | ||||
| Digital Input DI3 | Read | ||||
| Digital Input DI4 | Read | ||||
| Digital Input DI5 | Read | ||||
| Analog Input AI1 | Read | ||||
| Analog Input AI2 | Read |
Loading registers…
Send your device list
If a device is not in the library yet, we build the template for free as soon as we have the register data.
Use cases
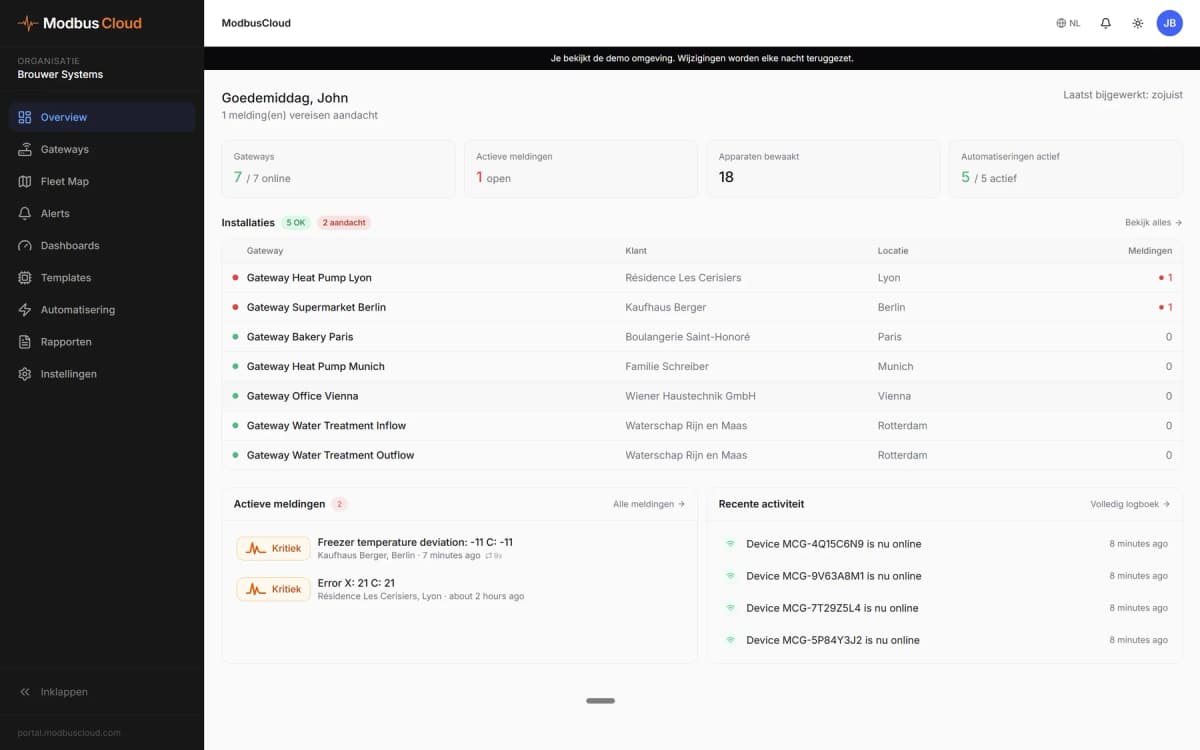
- Show output frequency, motor current and power of every pump or fan drive on a ModbusCloud dashboard.
- Get an email alert when the last fault code changes from 0 or the drive temperature passes a limit.
- Keep 365 days of energy counter and run time history to compare pump consumption per month.
- Change the PID setpoint of a pressure booster set remotely without visiting the plant room.
- Start, stop or adjust the speed reference from an automation on a time schedule.
Installation
Connect the EIA-485 terminals of the drive to RS485 A and B on the ModbusCloud Gateway and terminate the bus at both ends.
Set 9802 COMM PROT SEL to STD MODBUS, then station ID, baud rate and parity in group 53, and power cycle the drive.
For control over Modbus, set 1001 EXT1 COMMANDS and 1103 REF1 SELECT to COMM, and 1604 FAULT RESET SEL if you want remote reset.
In ModbusCloud, add a Modbus device (RTU) with the same address and serial settings, for example 1, 9600 baud, 8N1, and import this template.
Check that output frequency and motor current match the control panel.
Things to watch for
The drive does not answer. What should I check?
Check that 9802 is set to STD MODBUS and that station ID, baud rate and parity in group 53 match the device in ModbusCloud. New communication settings only take effect after a power cycle. Then swap A and B and check the termination at both ends of the bus.
Why do frequency or current look ten times too large?
The drive sends integers. Output frequency and current use 1 = 0.1 Hz and 1 = 0.1 A; the template already applies that scale. If you read the same values through Actual Value 1 to 8, the scale follows the signal selected in 5310 to 5317.
Changed parameters are gone after a power cycle. Why?
Parameter writes over Modbus are volatile. Write 1607 PARAM SAVE to store all changed values in permanent memory. Do this after the values are right, not on every write.
What should I keep in mind when writing the control word or parameters?
The control word and references only act when 1001 or 1002 and 1103 or 1106 are set to COMM, and the bits differ between the ABB drives and DCU profile in 5305. Writing a parameter while the drive runs can be refused. Change motor and limit settings only when you know the installation.




Want to see how it works?