
Danfoss VLT AQUA Drive FC 202
Frequency converter for pumps and blowers in water and wastewater, with built-in PID and pump control.
The Danfoss VLT AQUA Drive FC 202 is a frequency converter that controls the speed of pumps and blowers in water supply and wastewater treatment. This Modbus RTU template reads frequency, current, power, temperatures, feedback and alarm words, and lets you start, stop and set the speed, ramps, limits and PID setpoints from ModbusCloud.
- Protocol
- Modbus RTU
- Connection
- RS485, 9600 baud
- Registers
- 1000, read and write
- Brand
- Danfoss
- Key readings
- Output frequency · Motor current · Motor power · DC link voltage · Heat sink temperature · Feedback value · Alarm and warning words · Running hours and energy
- Available commands
- Start, stop and reset · Speed reference · Ramp times · Speed limits · Closed-loop setpoints · Pump and application settings
- Compatible models
- VLT AQUA Drive FC 202
- Last updated
Registers (1000)
1000 read, 728 write
| Name | Unit | Access | Address (Hidden until you confirm your email) | Function (hidden) | Type (hidden) |
|---|---|---|---|---|---|
| Control Word | Read | ||||
| Reference [Unit] | Read | ||||
| Reference % | % | Read and write | |||
| Status Word | Read | ||||
| Main Actual Value [%] | % | Read | |||
| Custom Readout | Read | ||||
| Power [kW] | kW | Read | |||
| Power [hp] | Read | ||||
| Motor Voltage 16-12 | V | Read | |||
| Frequency | Hz | Read | |||
| Motor Current 16-14 | A | Read | |||
| Frequency [%] | % | Read | |||
| Torque [Nm] | Nm | Read | |||
| Speed [RPM] | rpm | Read | |||
| Motor Thermal | % | Read | |||
| Thermistor Sensor Temperature | °C | Read | |||
| Motor Angle | Read | ||||
| Torque [%] | % | Read | |||
| Motor Shaft Power [kW] | kW | Read | |||
| Calibrated Stator Resistance | Read | ||||
| Power Filtered [kW] | kW | Read | |||
| Power Filtered [hp] | Read | ||||
| DC Link Voltage | V | Read | |||
| System Temp. | °C | Read | |||
| Brake Energy/s | kW | Read | |||
| Brake Energy Average | kW | Read | |||
| Heat Sink Temp. | °C | Read | |||
| Inverter Thermal | % | Read | |||
| Inv. Nom. Current | A | Read and write | |||
| Inv. Max. Current | A | Read and write | |||
| SL Controller State | Read | ||||
| Control Card Temp. | °C | Read | |||
| Logging Buffer Full | Read and write | ||||
| Service Log Counter | Read | ||||
| Timed Actions Status | Read | ||||
| Speed Error [RPM] | rpm | Read | |||
| Motor Phase U Current | A | Read | |||
| Motor Phase V Current | A | Read | |||
| Motor Phase W Current | A | Read | |||
| Speed Ref. After Ramp [RPM] | rpm | Read | |||
| Current Fault Source | Read | ||||
| External Reference | Read | ||||
| Feedback[Unit] | Read | ||||
| Digi Pot Reference | Read | ||||
| Feedback 1 [Unit] | Read | ||||
| Feedback 2 [Unit] | Read | ||||
| Feedback 3 [Unit] | Read | ||||
| PID Output [%] | % | Read | |||
| Adjusted Setpoint | Read | ||||
| Digital Input | Read and write | ||||
| Terminal 53 Switch Setting | Read | ||||
| Analog Input 53 | Read | ||||
| Terminal 54 Switch Setting | Read | ||||
| Analog Input 54 | Read | ||||
| Analog Output 42 [mA] | mA | Read | |||
| Digital Output [bin] | Read | ||||
| Freq. Input #29 [Hz] | Hz | Read | |||
| Freq. Input #33 [Hz] | Hz | Read | |||
| Pulse Output #27 [Hz] | Hz | Read | |||
| Pulse Output #29 [Hz] | Hz | Read | |||
| Relay Output [bin] | Read | ||||
| Counter A | Read | ||||
| Counter B | Read | ||||
| Analog In X30/11 | Read | ||||
| Analog In X30/12 | Read | ||||
| Analog Out X30/8 [mA] | mA | Read | |||
| Analog Out X45/1 [mA] | mA | Read | |||
| Analog Out X45/3 [mA] | mA | Read | |||
| Fieldbus CTW 1 | Read | ||||
| Fieldbus REF 1 | Read | ||||
| Comm. Option STW | Read | ||||
| FC Port CTW 1 | Read | ||||
| FC Port REF 1 | Read | ||||
| Bus Readout Alarm/Warning | Read | ||||
| Configurable Alarm/Warning Word | Read | ||||
| Alarm Word | Read | ||||
| Alarm Word 2 | Read | ||||
| Warning Word | Read | ||||
| Warning Word 2 | Read | ||||
| Ext. Status Word | Read and write | ||||
| Ext. Status Word 2 | Read | ||||
| Maintenance Word | Read | ||||
| Alarm Word 3 | Read | ||||
| Warning Word 3 | Read | ||||
| Ext. Status Word 3 | Read | ||||
| Maintenance Log: Item | Read | ||||
| Maintenance Log: Action | Read | ||||
| Maintenance Log: Time | s | Read | |||
| Maintenance Log: Date and Time | Read | ||||
| Emergency Mode Log: Event | Read | ||||
| Emergency Mode Log: Time | s | Read | |||
| Emergency Mode Log: Date and Time | Read | ||||
| Parameter Number | Read | ||||
| Parameter Index | Read | ||||
| Change Time | Read | ||||
| Operating Hours 18-16 | Read | ||||
| Running Hours 18-17 | Read | ||||
| Value Before Change as Integer | Read | ||||
| Value Before Change | Read | ||||
| Analog Input X42/1 | Read | ||||
| Analog Input X42/3 | Read | ||||
| Analog Input X42/5 | Read | ||||
| Analog Input X42/7 [V] | V | Read | |||
| Analog Input X42/9 [V] | V | Read | |||
| Analog Input X42/11 [V] | V | Read | |||
| Analog Input X48/2 [mA] | mA | Read | |||
| Temp. Input X48/4 | Read | ||||
| Temp. Input X48/7 | Read | ||||
| Temp. Input X48/10 | Read | ||||
| Analog Input X49/1 | Read | ||||
| Analog Input X49/3 | Read | ||||
| Analog Input X49/5 | Read | ||||
| Analog Input X49/7 | Read | ||||
| Analog Input X49/9 | Read | ||||
| Analog Input X49/11 | Read | ||||
| X49 Digital Output [bin] | Read | ||||
| Last Warning | Read | ||||
| Last Warning Count | Read | ||||
| Sensorless Readout [Unit] | Read | ||||
| Active Alarm Numbers | Read | ||||
| Active Warning Numbers | Read | ||||
| Digital Input 2 | Read | ||||
| AMA Status | Read | ||||
| Actual Switching Frequency | Read | ||||
| Alarm Word 4 | Read | ||||
| Warning Word 4 | Read | ||||
| Mains Voltage | V | Read | |||
| Mains Frequency | Hz | Read | |||
| Mains Imbalance | % | Read | |||
| Worst Inrush | Read | ||||
| Inrush Mode | Read | ||||
| Rectifier DC Volt | V | Read | |||
| Mains Voltage 2 | V | Read | |||
| Mains Frequency 2 | Hz | Read | |||
| Mains Imbalance 2 | % | Read | |||
| Rectifier DC Volt. 2 | V | Read | |||
| Component Temp. | °C | Read | |||
| Auxiliary Temp. | °C | Read | |||
| Component SW ID | Read | ||||
| HS Temp. ph.U | °C | Read | |||
| HS Temp. ph.V | °C | Read | |||
| HS Temp. ph.W | °C | Read | |||
| PC Fan A Speed | rpm | Read | |||
| PC Fan B Speed | rpm | Read | |||
| PC Fan C Speed | rpm | Read | |||
| FPC Fan A Speed | rpm | Read | |||
| FPC Fan B Speed | rpm | Read | |||
| FPC Fan C Speed | rpm | Read | |||
| FPC Fan D Speed | rpm | Read | |||
| FPC Fan E Speed | rpm | Read | |||
| FPC Fan F Speed | rpm | Read | |||
| Warning Log: Warning Number | Read | ||||
| Warning Log: Value | Read | ||||
| Warning Log: Time | s | Read | |||
| Warning Log: Date and Time | Read | ||||
| Warning Log: Setpoint | Read | ||||
| Warning Log: Feedback | Read | ||||
| Warning Log: Current Demand | % | Read | |||
| Warning Log: Process Ctrl Unit | Read | ||||
| Warning Log: Speed | rpm | Read | |||
| Warning Log: Duration | s | Read | |||
| Warning Log: Ext. Reference | % | Read | |||
| Warning Log: Frequency | Hz | Read | |||
| Warning Log: Current | A | Read | |||
| Warning Log: Voltage | V | Read | |||
| Warning: DC Link Voltage | V | Read | |||
| Warning Log: Control Word | Read | ||||
| Warning Log: Torque | Nm | Read | |||
| Audit Log: Event | Read | ||||
| Audit Log: Account | Read | ||||
| Audit Log: Channel | Read | ||||
| Audit Log: Operating Seconds | s | Read | |||
| Audit Log: Date and Time | Read | ||||
| Warning Log: Status Word | Read | ||||
| Main Actual Value | % | Read | |||
| Bus Status Word | Read | ||||
| Last Fault Code | Read | ||||
| Status Word Coil Control Ready | Read | ||||
| Output Value Coil Bit 00 | Read | ||||
| Status Word Coil Drive Ready | Read | ||||
| Output Value Coil Bit 01 | Read | ||||
| Status Word Coil Coasting Stop | Read | ||||
| Output Value Coil Bit 02 | Read | ||||
| Status Word Coil Alarm | Read | ||||
| Output Value Coil Bit 03 | Read | ||||
| Status Word Coil Bit 04 | Read | ||||
| Output Value Coil Bit 04 | Read | ||||
| Status Word Coil Bit 05 | Read | ||||
| Output Value Coil Bit 05 | Read | ||||
| Status Word Coil Bit 06 | Read | ||||
| Output Value Coil Bit 06 | Read | ||||
| Status Word Coil Warning | Read | ||||
| Output Value Coil Bit 07 | Read | ||||
| Status Word Coil At Reference | Read | ||||
| Output Value Coil Bit 08 | Read | ||||
| Status Word Coil Hand or Auto | Read | ||||
| Output Value Coil Bit 09 | Read | ||||
| Status Word Coil In Frequency Range | Read | ||||
| Output Value Coil Bit 10 | Read | ||||
| Status Word Coil Running | Read | ||||
| Output Value Coil Bit 11 | Read | ||||
| Status Word Coil Bit 12 | Read | ||||
| Output Value Coil Bit 12 | Read | ||||
| Status Word Coil Voltage Warning | Read | ||||
| Output Value Coil Bit 13 | Read | ||||
| Status Word Coil Current Limit | Read | ||||
| Output Value Coil Bit 14 | Read | ||||
| Status Word Coil Thermal Warning | Read | ||||
| Output Value Coil Bit 15 | Read | ||||
| Bus Control Word | Read and write | ||||
| Bus Reference | % | Read and write | |||
| Parameter Array Index | Read and write | ||||
| Control Word Coil Preset Reference LSB | Read and write | ||||
| Reference Coil Bit 00 | Read and write | ||||
| Control Word Coil Preset Reference MSB | Read and write | ||||
| Reference Coil Bit 01 | Read and write | ||||
| Control Word Coil DC Brake | Read and write | ||||
| Reference Coil Bit 02 | Read and write | ||||
| Control Word Coil Coast Stop | Read and write | ||||
| Reference Coil Bit 03 | Read and write | ||||
| Control Word Coil Quick Stop | Read and write | ||||
| Reference Coil Bit 04 | Read and write | ||||
| Control Word Coil Freeze Frequency | Read and write | ||||
| Reference Coil Bit 05 | Read and write | ||||
| Control Word Coil Ramp Stop or Start | Read and write | ||||
| Reference Coil Bit 06 | Read and write | ||||
| Control Word Coil Reset | Read and write | ||||
| Reference Coil Bit 07 | Read and write | ||||
| Control Word Coil Jog | Read and write | ||||
| Reference Coil Bit 08 | Read and write | ||||
| Control Word Coil Ramp 1 or 2 | Read and write | ||||
| Reference Coil Bit 09 | Read and write | ||||
| Control Word Coil Data Valid | Read and write | ||||
| Reference Coil Bit 10 | Read and write | ||||
| Control Word Coil Relay 1 | Read and write | ||||
| Reference Coil Bit 11 | Read and write | ||||
| Control Word Coil Relay 2 | Read and write | ||||
| Reference Coil Bit 12 | Read and write | ||||
| Control Word Coil Set-up LSB | Read and write | ||||
| Reference Coil Bit 13 | Read and write | ||||
| Control Word Coil Set-up MSB | Read and write | ||||
| Reference Coil Bit 14 | Read and write | ||||
| Control Word Coil Reversing | Read and write | ||||
| Reference Coil Bit 15 | Read and write | ||||
| Parameter Write to EEPROM | Read and write | ||||
| Language | Read and write | ||||
| Motor Speed Unit | Read and write | ||||
| Regional Setting | Read and write | ||||
| Operating State at Power-up (Hand) | Read and write | ||||
| Local Mode Unit | Read and write | ||||
| Active Set-up | Read and write | ||||
| Edit Set-up | Read and write | ||||
| This Set-up Linked to | Read and write | ||||
| Readout: Linked Set-ups | Read | ||||
| Readout: Edit Set-ups/Channel | Read | ||||
| Readout: Actual Setup | Read | ||||
| Active Emergency Setup | Read | ||||
| Display Line 1.1 Small | Read and write | ||||
| My Personal Menu | Read and write | ||||
| Custom Readout Unit | Read and write | ||||
| Min Value of User-defined Readout | Read | ||||
| Custom Readout Max Value | Read | ||||
| System Use Notification Text | Read and write | ||||
| Display Text 2 | Read and write | ||||
| Display Text 3 | Read and write | ||||
| [Hand On] Key on LCP | Read and write | ||||
| [Off] Key on LCP | Read and write | ||||
| [Auto On] Key on LCP | Read and write | ||||
| [Reset] Key on LCP | Read and write | ||||
| [Off/Reset] Key on LCP | Read and write | ||||
| [Drive Bypass] Key on LCP | Read and write | ||||
| LCP Copy | Read and write | ||||
| Set-up Copy | Read and write | ||||
| Main Menu Password | Read and write | ||||
| Access to Main Menu w/o Password | Read and write | ||||
| Personal Menu Password | Read and write | ||||
| Access to Personal Menu w/o Password | Read and write | ||||
| Bus Password Access | Read and write | ||||
| Date and Time | Read and write | ||||
| Date Format | Read and write | ||||
| Time Format | Read and write | ||||
| Time Zone Offset | min | Read and write | |||
| DST/Summertime | Read and write | ||||
| Last Power Off Time | Read | ||||
| DST/Summertime Start | Read and write | ||||
| Clock Fault | Read and write | ||||
| Working Days | Read and write | ||||
| Additional Working Days | Read and write | ||||
| Additional Non-working Days | Read and write | ||||
| Time for Fieldbus | Read and write | ||||
| Summer Time End for Fieldbus | Read and write | ||||
| Clock Restore at Powerup | Read and write | ||||
| Date and Time Readout | Read | ||||
| Integrity Check at Power-up | Read and write | ||||
| Checksum (SHA256) | Read | ||||
| Session Timeout (in Seconds) | s | Read and write | |||
| Max Login Attempts | Read and write | ||||
| Warning LED Blinking | Read and write | ||||
| Configuration Mode | Read and write | ||||
| Motor Control Principle | Read and write | ||||
| Torque Characteristics | Read and write | ||||
| Overload Mode | Read and write | ||||
| Local Mode Configuration | Read and write | ||||
| Clockwise Direction | Read and write | ||||
| Motor Construction | Read and write | ||||
| Damping Gain | % | Read and write | |||
| Low Speed Filter Time Const. | s | Read and write | |||
| High Speed Filter Time Const. | s | Read and write | |||
| Voltage Filter Time Const. | s | Read and write | |||
| Motor Power [kW] | kW | Read and write | |||
| Motor Power [HP] | Read and write | ||||
| Motor Voltage 1-22 | V | Read and write | |||
| Motor Frequency 1-23 | Hz | Read and write | |||
| Motor Current 1-24 | A | Read and write | |||
| Motor Nominal Speed | rpm | Read and write | |||
| Motor Cont. Rated Torque | Nm | Read and write | |||
| Motor Rotation Check | Read and write | ||||
| Automatic Motor Adaptation (AMA) | Read and write | ||||
| Stator Resistance (Rs) | Read and write | ||||
| Rotor Resistance (Rr) | Read and write | ||||
| Stator Leakage Reactance (X1) | Read and write | ||||
| Rotor Leakage Reactance (X2) | Read and write | ||||
| Main Reactance (Xh) | Read and write | ||||
| Iron Loss Resistance (Rfe) | Read and write | ||||
| d-axis Inductance (Ld) | Read and write | ||||
| q-axis Inductance (Lq) | Read and write | ||||
| Motor Poles | Read and write | ||||
| Back EMF at 1000 RPM | V | Read and write | |||
| d-axis Inductance Sat. (LdSat) | Read and write | ||||
| q-axis Inductance Sat. (LqSat) | Read and write | ||||
| Position Detection Gain | % | Read and write | |||
| Torque Calibration | Read and write | ||||
| d-axis Inductance Sat. Point | % | Read and write | |||
| q-axis Inductance Sat. Point | % | Read and write | |||
| Motor Magnetization at Zero Speed | % | Read and write | |||
| Min Speed Normal Magnetising [RPM] | rpm | Read and write | |||
| Min Speed Normal Magnetising [Hz] | Hz | Read and write | |||
| Model Shift Frequency | Hz | Read and write | |||
| Voltage Reduction in Fieldweakening | V | Read and write | |||
| U/f Characteristic - U | Read and write | ||||
| U/f Characteristic - F | Read and write | ||||
| Flying Start Test Pulses Current | % | Read and write | |||
| Flying Start Test Pulses | % | Read and write | |||
| Low Speed Load Compensation | % | Read and write | |||
| High Speed Load Compensation | % | Read and write | |||
| Slip Compensation | % | Read and write | |||
| Slip Compensation Time Constant | s | Read and write | |||
| Resonance Damping | % | Read and write | |||
| Resonance Damping Time Constant | ms | Read and write | |||
| Min. Current at Low Speed | % | Read and write | |||
| Motor Inertia | Read and write | ||||
| System Inertia | Read and write | ||||
| Start Mode | Read and write | ||||
| Start Delay | s | Read and write | |||
| Start Function | Read and write | ||||
| Flying Start | Read and write | ||||
| Compressor Start Max Speed [RPM] | rpm | Read and write | |||
| Compressor Start Max Speed [Hz] | Hz | Read and write | |||
| Compressor Start Max Time to Trip | s | Read and write | |||
| Function at Stop | Read and write | ||||
| Min Speed for Function at Stop [RPM] | rpm | Read and write | |||
| Trip Speed Low [RPM] | rpm | Read and write | |||
| Trip Speed Low [Hz] | Hz | Read and write | |||
| Motor Thermal Protection | Read and write | ||||
| Motor External Fan | Read and write | ||||
| Thermistor Resource | Read and write | ||||
| ATEX ETR Cur. Lim. Speed Reduction | % | Read and write | |||
| Thermistor Sensor Type | Read and write | ||||
| Thermistor Sensor Resource | Read and write | ||||
| Thermistor Threshold Level | °C | Read and write | |||
| ATEX ETR Interpol. Points Freq. | Read and write | ||||
| ATEX ETR Interpol. Points Current | Read and write | ||||
| DC Hold/Preheat | % | Read and write | |||
| DC Brake Current | % | Read and write | |||
| DC Braking Time | s | Read and write | |||
| DC Brake Cut In Speed [RPM] | rpm | Read and write | |||
| Parking Current | % | Read and write | |||
| Parking Time | s | Read and write | |||
| Brake Function | Read and write | ||||
| Brake Resistor (ohm) 2-11 | Read and write | ||||
| Brake Power Limit (kW) | kW | Read and write | |||
| Brake Power Monitoring | Read and write | ||||
| Brake Check | Read and write | ||||
| AC Brake Max. Current | % | Read and write | |||
| Over-voltage Control | Read and write | ||||
| Over-voltage Gain | % | Read and write | |||
| Minimum Reference | Read and write | ||||
| Maximum Reference | Read and write | ||||
| Reference Function | Read and write | ||||
| On Reference Window | Read and write | ||||
| Preset Reference | % | Read and write | |||
| Jog Speed [Hz] | Hz | Read and write | |||
| Reference Site | Read and write | ||||
| Preset Relative Reference | % | Read and write | |||
| Reference Resource 1 | Read and write | ||||
| Reference Resource 3 | Read and write | ||||
| Jog Speed [RPM] | rpm | Read and write | |||
| Ramp 1 Ramp Up Time | s | Read and write | |||
| Ramp 1 Ramp Down Time | s | Read and write | |||
| Ramp 2 Ramp Up Time | s | Read and write | |||
| Ramp 2 Ramp Down Time | s | Read and write | |||
| Jog Ramp Time | s | Read and write | |||
| Quick Stop Ramp Time | s | Read and write | |||
| Initial Ramp Time | s | Read and write | |||
| Check Valve Ramp | s | Read and write | |||
| Check Valve Ramp End Speed [RPM] | rpm | Read and write | |||
| Check Valve Ramp End Speed [Hz] | Hz | Read and write | |||
| Final Ramp Time | s | Read and write | |||
| Step Size | % | Read and write | |||
| Ramp Time | s | Read and write | |||
| Power Restore | Read and write | ||||
| Maximum Limit | % | Read and write | |||
| Minimum Limit | % | Read and write | |||
| Ramp Delay | Read and write | ||||
| Motor Speed Direction | Read and write | ||||
| Motor Speed Low Limit [RPM] | rpm | Read and write | |||
| Motor Speed Low Limit [Hz] | Hz | Read and write | |||
| Motor Speed High Limit [RPM] | rpm | Read and write | |||
| Motor Speed High Limit [Hz] | Hz | Read and write | |||
| Torque Limit Motor Mode | % | Read and write | |||
| Torque Limit Generator Mode | % | Read and write | |||
| Current Limit | % | Read and write | |||
| Max Output Frequency | Hz | Read and write | |||
| Motor Protection Current Limit | A | Read and write | |||
| Motor Protection Reaction Time | Read and write | ||||
| Motor Check Time Interval | Read and write | ||||
| Warning Current Low | A | Read and write | |||
| Warning Current High | Read and write | ||||
| Warning Speed Low | rpm | Read and write | |||
| Warning Speed High | rpm | Read and write | |||
| Warning Reference Low | Read and write | ||||
| Warning Reference High | Read and write | ||||
| Warning Feedback Low | Read and write | ||||
| Warning Feedback High | Read and write | ||||
| Missing Motor Phase Function | Read and write | ||||
| Bypass Speed From [RPM] | rpm | Read and write | |||
| Bypass Speed From [Hz] | Hz | Read and write | |||
| Bypass Speed To [RPM] | rpm | Read and write | |||
| Bypass Speed To [Hz] | Hz | Read and write | |||
| Semi-auto Bypass Set-up | Read and write | ||||
| Digital I/O Mode | Read and write | ||||
| Terminal 27 Mode | Read and write | ||||
| Terminal 29 Mode | Read and write | ||||
| Terminal 18 Digital Input | Read and write | ||||
| Terminal 19 Digital Input | Read and write | ||||
| Terminal 27 Digital Input | Read and write | ||||
| Terminal 29 Digital Input | Read and write | ||||
| Terminal 32 Digital Input | Read and write | ||||
| Terminal 33 Digital Inputs | Read and write | ||||
| Terminal X30/2 | Read and write | ||||
| Terminal X30/3 Digital Input | Read and write | ||||
| Terminal X30/4 Digital Input | Read and write | ||||
| Terminal X46/3 Digital Input | Read and write | ||||
| Terminal X46/5 Digital Input | Read and write | ||||
| Terminal X46/7 Digital Input | Read and write | ||||
| Terminal X46/9 | Read and write | ||||
| Terminal X46/11 Digital Input | Read and write | ||||
| Terminal X46/13 Digital Input | Read and write | ||||
| Terminal 27 Digital Output | Read and write | ||||
| Terminal 29 Digital Output | Read and write | ||||
| Term X30/6 Digi Out (MCB 101) | Read and write | ||||
| Term X30/7 Digi Out (MCB 101) | Read and write | ||||
| Function Relays | Read and write | ||||
| On Delay, Relay | s | Read and write | |||
| Off Delay, Relay | s | Read and write | |||
| Term. 29 Low Frequency | Hz | Read and write | |||
| Term. 29 High Frequency | Hz | Read and write | |||
| Term. 29 Low Ref./Feedb. Value | Read and write | ||||
| Term. 29 High Ref./Feedb. Value | Read and write | ||||
| Pulse Filter Time Constant #29 | ms | Read and write | |||
| Term. 33 Low Frequency | Hz | Read and write | |||
| Term. 33 High Frequency | Hz | Read and write | |||
| Term. 33 Low Ref./Feedb. Value | Read and write | ||||
| Term. 33 High Ref./Feedb. Value | Read and write | ||||
| Pulse Filter Time Constant #33 | ms | Read and write | |||
| Terminal 27 Pulse Output Variable | Read and write | ||||
| Pulse Output Max Freq #27 | Hz | Read and write | |||
| Terminal 29 Pulse Output Variable | Read and write | ||||
| Pulse Output Max Freq #29 | Hz | Read and write | |||
| Terminal X30/6 Pulse Output Variable | Read and write | ||||
| Pulse Output Max Freq #30/6 | Hz | Read and write | |||
| AHF Cap Reconnect Delay | s | Read and write | |||
| Digital & Relay Bus Control | Read and write | ||||
| Application Bus Control | Read and write | ||||
| Pulse Out #27 Bus Control | % | Read and write | |||
| Pulse Out #27 Timeout Preset | % | Read and write | |||
| Pulse Out #29 Bus Control | % | Read and write | |||
| Pulse Out #29 Timeout Preset | % | Read and write | |||
| Pulse Out #30/6 Bus Control | % | Read and write | |||
| Pulse Out #30/6 Timeout Preset | % | Read and write | |||
| Live Zero Timeout Time | s | Read and write | |||
| Live Zero Timeout Function | Read and write | ||||
| Emergency Mode Live Zero Timeout Function | Read and write | ||||
| Terminal 53 Low Voltage | V | Read and write | |||
| Terminal 53 High Voltage | V | Read and write | |||
| Terminal 53 Low Current | mA | Read and write | |||
| Terminal 53 High Current | mA | Read and write | |||
| Terminal 53 Low Ref./Feedb. Value | Read and write | ||||
| Terminal 53 High Ref./Feedb. Value | Read and write | ||||
| Terminal 53 Filter Time Constant | s | Read and write | |||
| Terminal 53 Live Zero | Read and write | ||||
| Terminal 54 Low Voltage | V | Read and write | |||
| Terminal 54 High Voltage | V | Read and write | |||
| Terminal 54 Low Current | mA | Read and write | |||
| Terminal 54 High Current | mA | Read and write | |||
| Terminal 54 Low Ref./Feedb. Value | Read and write | ||||
| Terminal 54 High Ref./Feedb. Value | Read and write | ||||
| Terminal 54 Filter Time Constant | s | Read and write | |||
| Terminal 54 Live Zero | Read and write | ||||
| Terminal X30/11 Low Voltage | V | Read and write | |||
| Terminal X30/11 High Voltage | V | Read and write | |||
| Term. X30/11 Low Ref./Feedb. Value | Read and write | ||||
| Term. X30/11 High Ref./Feedb. Value | Read and write | ||||
| Term. X30/11 Filter Time Constant | s | Read and write | |||
| Terminal X30/11 Live Zero | Read and write | ||||
| X30/12 Low Voltage | V | Read and write | |||
| Terminal X30/12 High Voltage | V | Read and write | |||
| Term. X30/12 Low Ref./Feedb. Value | Read and write | ||||
| Term. X30/12 High Ref./Feedb. Value | Read and write | ||||
| X30/12 Filter Time Constant | s | Read and write | |||
| Terminal X30/12 Live Zero | Read and write | ||||
| Terminal 42 Output | Read and write | ||||
| Terminal 42 Output Min Scale | % | Read and write | |||
| Terminal 42 Output Max Scale | % | Read and write | |||
| Term 42 Output Bus Ctrl | % | Read and write | |||
| Term 42 Output Timeout Preset | % | Read and write | |||
| Analog Output Filter | Read and write | ||||
| Terminal X30/8 Output | Read and write | ||||
| Terminal X30/8 Min. Scale | % | Read and write | |||
| Terminal X30/8 Max. Scale | % | Read and write | |||
| Terminal X30/8 Bus Control | % | Read and write | |||
| Terminal X30/8 Output Timeout Preset | % | Read and write | |||
| Terminal X45/1 Output | Read and write | ||||
| Terminal X45/1 Min. Scale | % | Read and write | |||
| Terminal X45/1 Max. Scale | % | Read and write | |||
| Terminal X45/1 Bus Control | % | Read and write | |||
| Terminal X45/1 Output Timeout Preset | % | Read and write | |||
| Terminal X45/3 Output | Read and write | ||||
| Terminal X45/3 Min. Scale | % | Read and write | |||
| Terminal X45/3 Max. Scale | % | Read and write | |||
| Terminal X45/3 Bus Control | % | Read and write | |||
| Terminal X45/3 Output Timeout Preset | % | Read and write | |||
| Speed PID Proportional Gain | Read and write | ||||
| Speed PID Integral Time | ms | Read and write | |||
| Speed PID Differentiation Time | ms | Read and write | |||
| Speed PID Diff. Gain Limit | Read and write | ||||
| Speed PID Lowpass Filter Time | ms | Read and write | |||
| Speed PID Feed Forward Factor | % | Read and write | |||
| Control Site | Read and write | ||||
| Control Word Source | Read and write | ||||
| Control Word Timeout Time | s | Read and write | |||
| Control Word Timeout Function | Read and write | ||||
| End-of-Timeout Function | Read and write | ||||
| Reset Control Word Timeout | Read and write | ||||
| Diagnosis Trigger | Read and write | ||||
| Readout Filtering | Read and write | ||||
| Communication Charset | Read and write | ||||
| Control Word Profile | Read and write | ||||
| Configurable Control Word CTW | Read and write | ||||
| Configurable Alarm and Warning Word | Read and write | ||||
| Add Fieldbus ref. to Reference | Read and write | ||||
| Product Code | Read and write | ||||
| Invalid Memory Write Counter | Read and write | ||||
| Protocol | Read and write | ||||
| Address | Read and write | ||||
| FC Port Baud Rate | Read and write | ||||
| Parity/Stop Bits | Read and write | ||||
| Estimated Cycle Time | ms | Read and write | |||
| Minimum Response Delay | ms | Read and write | |||
| Max Response Delay | ms | Read and write | |||
| Max Inter-Char Delay | ms | Read and write | |||
| Protocol/Profile Firmware Version | Read | ||||
| Telegram Selection | Read and write | ||||
| PCD Write Configuration | Read and write | ||||
| PCD Read Configuration | Read and write | ||||
| BTM Transaction Status | Read | ||||
| BTM Timeout | s | Read and write | |||
| BTM Maximum Errors | Read and write | ||||
| Coasting Select | Read and write | ||||
| Quick Stop Select | Read and write | ||||
| DC Brake Select | Read and write | ||||
| Start Select | Read and write | ||||
| Reversing Select | Read and write | ||||
| Set-up Select | Read and write | ||||
| Preset Reference Select | Read and write | ||||
| BACnet Device Instance | Read and write | ||||
| MS/TP Max Masters | Read and write | ||||
| MS/TP Max Info Frames | Read and write | ||||
| I-AM Service | Read and write | ||||
| Initialization Password | Read and write | ||||
| Bus Message Count | Read | ||||
| Bus Error Count | Read | ||||
| Slave Error Count | Read | ||||
| Bus Jog 1 Speed | rpm | Read and write | |||
| Bus Jog 2 Speed | rpm | Read and write | |||
| Bus Feedback 1 | Read and write | ||||
| Bus Feedback 2 | Read and write | ||||
| Bus Feedback 3 | Read and write | ||||
| Response Error Codes | Read | ||||
| SL Controller Mode | Read and write | ||||
| Start Event | Read and write | ||||
| Stop Event | Read and write | ||||
| Reset SLC | Read and write | ||||
| Comparator Operand | Read and write | ||||
| Comparator Operator | Read and write | ||||
| Comparator Value | Read and write | ||||
| RS-FF Operand S | Read and write | ||||
| RS-FF Operand R | Read and write | ||||
| SL Controller Timer | Read and write | ||||
| Logic Rule Boolean 1 | Read and write | ||||
| Logic Rule Operator 1 | Read and write | ||||
| Logic Rule Boolean 2 | Read and write | ||||
| Logic Rule Operator 2 | Read and write | ||||
| Logic Rule Boolean 3 | Read and write | ||||
| SL Controller 1 Event | Read and write | ||||
| SL Controller 1 Action | Read and write | ||||
| SL Controller 2 Event | Read and write | ||||
| SL Controller 2 Action | Read and write | ||||
| SL Controller 3 Event | Read and write | ||||
| SL Controller 3 Action | Read and write | ||||
| SL Controller 4 Event | Read and write | ||||
| SL Controller 4 Action | Read and write | ||||
| Alert Trigger | Read and write | ||||
| Alert Action | Read and write | ||||
| Alert Text | Read and write | ||||
| Alert Alarm Word | Read | ||||
| Alert Warning Word | Read | ||||
| Alert Status Word | Read | ||||
| Switching Pattern | Read and write | ||||
| Switching Frequency | Read and write | ||||
| Switching Pattern Shift Frequency | Hz | Read and write | |||
| Overmodulation | Read and write | ||||
| Acoustic Noise Reduction | Read and write | ||||
| PWM Generation | Read and write | ||||
| Mains Failure | Read and write | ||||
| Response to Mains Imbalance | Read and write | ||||
| Kin. Back-up Time-up | s | Read and write | |||
| Kin. Back-up Trip Recovery Level | Read and write | ||||
| Kin. Back-up Gain | % | Read and write | |||
| Fast Mains Phase Loss Level | % | Read and write | |||
| Fast Mains Phase Loss Min Power | % | Read and write | |||
| Reset Mode | Read and write | ||||
| Automatic Restart Time | s | Read and write | |||
| Operation Mode | Read and write | ||||
| Trip Delay at Current Limit | s | Read and write | |||
| Trip Delay at Torque Limit | s | Read and write | |||
| Trip Delay at Inverter Fault | s | Read and write | |||
| Current Lim Ctrl, Proportional Gain | % | Read and write | |||
| Current Lim Ctrl, Integration Time | s | Read and write | |||
| Current Lim Ctrl, Filter Time | ms | Read and write | |||
| Stall Protection | Read and write | ||||
| VT Level | % | Read and write | |||
| AEO Minimum Magnetization | % | Read and write | |||
| Minimum AEO Frequency | Hz | Read and write | |||
| Motor Cosphi | Read and write | ||||
| d-axis Reference Gain | % | Read and write | |||
| RFI Filter | Read and write | ||||
| DC-link Compensation | Read and write | ||||
| Fan Control | Read and write | ||||
| Fan Monitor | Read and write | ||||
| Output Filter | Read and write | ||||
| Capacitance Output Filter | Read and write | ||||
| Inductance Output Filter | Read and write | ||||
| Actual Number of Inverter Units | Read and write | ||||
| Function at Over Temperature | Read and write | ||||
| Function at Inverter Overload | Read and write | ||||
| Inv. Overload Derate Current | % | Read and write | |||
| Option Supplied by External 24VDC | Read and write | ||||
| Option Data Storage | Read and write | ||||
| Fault Level | Read and write | ||||
| Feedback 1 Source | Read and write | ||||
| Feedback 1 Conversion | Read and write | ||||
| Feedback 1 Source Unit | Read and write | ||||
| Feedback 2 Source | Read and write | ||||
| Feedback 2 Conversion | Read and write | ||||
| Feedback 2 Source Unit | Read and write | ||||
| Feedback 3 Source | Read and write | ||||
| Feedback 3 Conversion | Read and write | ||||
| Feedback 3 Source Unit | Read and write | ||||
| Reference/Feedback Unit | Read and write | ||||
| Setpoint 1 | Read and write | ||||
| Setpoint 2 | Read and write | ||||
| Setpoint 3 | Read and write | ||||
| Controller Selection | Read and write | ||||
| Gain Estimate | Read and write | ||||
| Time Constant Estimate | s | Read and write | |||
| Deadtime Estimate | s | Read and write | |||
| Controller Gain | Read and write | ||||
| Tuned Cascade Capacity | % | Read and write | |||
| Sensorless Unit | Read and write | ||||
| Sensorless Information | Read | ||||
| Closed Loop Type 20-70 | Read and write | ||||
| PID Performance 20-71 | Read and write | ||||
| PID Output Change 20-72 | Read and write | ||||
| Minimum Feedback Level 20-73 | Read and write | ||||
| Maximum Feedback Level 20-74 | Read and write | ||||
| Autotuning | Read and write | ||||
| PID Normal/Inverse Control | Read and write | ||||
| PID Start Speed [RPM] | rpm | Read and write | |||
| PID Start Speed [Hz] | Hz | Read and write | |||
| On Reference Bandwidth | % | Read and write | |||
| PID Anti Windup | Read and write | ||||
| PID Proportional Gain | Read and write | ||||
| PID Integral Time | s | Read and write | |||
| PID Differentiation Time | s | Read and write | |||
| PID Diff. Gain Limit | Read and write | ||||
| Closed Loop Type 21-00 | Read and write | ||||
| PID Performance 21-01 | Read and write | ||||
| PID Output Change 21-02 | Read and write | ||||
| Minimum Feedback Level 21-03 | Read and write | ||||
| Maximum Feedback Level 21-04 | Read and write | ||||
| PID Autotuning | Read and write | ||||
| Ext. 1 Ref./Feedback Unit | Read and write | ||||
| Ext. 1 Minimum Reference | Read and write | ||||
| Ext. Maximum Reference | Read and write | ||||
| Ext. 1 Reference Source | Read and write | ||||
| Ext. 1 Feedback Source | Read and write | ||||
| Ext. 1 Setpoint | Read and write | ||||
| Ext. Reference [Unit] | Read | ||||
| Ext. 1 Feedback [Unit] | Read | ||||
| Ext. 1 Output [%] | % | Read | |||
| Ext. 1 Normal/Inverse Control | Read and write | ||||
| Ext. 1 Proportional Gain | Read and write | ||||
| Ext. 1 Integral Time | s | Read and write | |||
| Ext. 1 Differentiation Time | s | Read and write | |||
| Ext. 1 Dif. Gain Limit | Read and write | ||||
| Ext. 1 On Reference Bandwidth | % | Read and write | |||
| Ext. 2 Ref./Feedback Unit | Read and write | ||||
| Ext. 2 Minimum Reference | Read and write | ||||
| Ext. 2 Maximum Reference | Read and write | ||||
| Ext. 2 Reference Source | Read and write | ||||
| Ext. 2 Feedback Source | Read and write | ||||
| Ext. 2 Setpoint | Read and write | ||||
| Ext. 2 Reference [Unit] | Read | ||||
| Ext. 2 Feedback [Unit] | Read | ||||
| Ext. 2 Output [%] | % | Read | |||
| Ext. 2 Normal/Inverse Control | Read and write | ||||
| Ext. 2 Proportional Gain | Read and write | ||||
| Ext. 2 Integral Time | s | Read and write | |||
| Ext. 2 Differentiation Time | s | Read and write | |||
| Ext. 2 Dif. Gain Limit | Read and write | ||||
| Ext. 2 On Reference Bandwidth | % | Read and write | |||
| Ext. 3 Ref./Feedback Unit | Read and write | ||||
| Ext. 3 Minimum Reference | Read and write | ||||
| Ext. 3 Maximum Reference | Read and write | ||||
| Ext. 3 Reference Source | Read and write | ||||
| Ext. 3 Feedback Source | Read and write | ||||
| Ext. 3 Setpoint | Read and write | ||||
| Ext. 3 Reference [Unit] | Read | ||||
| Ext. 3 Feedback [Unit] | Read | ||||
| Ext. 3 Output [%] | % | Read | |||
| Ext. 3 Normal/Inverse Control | Read and write | ||||
| Ext. 3 Proportional Gain | Read and write | ||||
| Ext. 3 Integral Time | s | Read and write | |||
| Ext. 3 Differentiation Time | s | Read and write | |||
| Ext. 3 Dif. Gain Limit | Read and write | ||||
| Ext. 3 On Reference Bandwidth | % | Read and write | |||
| External Interlock Delay | s | Read and write | |||
| Power Filter Time | s | Read and write | |||
| Low Power Auto Set-up | Read and write | ||||
| Low Power Detection | Read and write | ||||
| Low Speed Detection | Read and write | ||||
| No-flow Detection | Read and write | ||||
| No-flow Delay | s | Read and write | |||
| Dry Pump Function | Read and write | ||||
| Dry Pump Delay | s | Read and write | |||
| No-flow Low Speed [RPM] | rpm | Read and write | |||
| No-flow Low Speed [Hz] | Hz | Read and write | |||
| No-flow Power | kW | Read | |||
| Power Correction Factor | % | Read and write | |||
| Low Speed [RPM] 22-32 | rpm | Read and write | |||
| Low Speed [Hz] 22-33 | Hz | Read and write | |||
| Low Speed Power [kW] 22-34 | kW | Read and write | |||
| Low Speed Power [hp] 22-35 | Read and write | ||||
| High Speed [RPM] 22-36 | rpm | Read and write | |||
| High Speed [Hz] 22-37 | Hz | Read and write | |||
| High Speed Power [kW] 22-38 | kW | Read and write | |||
| High Speed Power [hp] 22-39 | Read and write | ||||
| Minimum Run Time 22-40 | s | Read and write | |||
| Minimum Sleep Time | s | Read and write | |||
| Wake-up Speed [RPM] | rpm | Read and write | |||
| Wake-up Speed [Hz] | Hz | Read and write | |||
| Wake-up Ref./FB Difference | % | Read and write | |||
| Setpoint Boost | % | Read and write | |||
| Maximum Boost Time | s | Read and write | |||
| End of Curve Function | Read and write | ||||
| End of Curve Delay | s | Read and write | |||
| Broken Belt Function | Read and write | ||||
| Broken Belt Torque | % | Read and write | |||
| Broken Belt Delay | s | Read and write | |||
| Short Cycle Protection | Read and write | ||||
| Interval between Starts | s | Read and write | |||
| Minimum Run Time 22-77 | s | Read and write | |||
| Minimum Run Time Override | Read and write | ||||
| Minimum Run Time Override Value | Read and write | ||||
| Flow Compensation | Read and write | ||||
| Square-Linear Curve Approximation | % | Read and write | |||
| Work Point Calculation | Read and write | ||||
| Speed at No-Flow [RPM] | rpm | Read and write | |||
| Speed at No-Flow [Hz] | Hz | Read and write | |||
| Speed at Design Point [RPM] | rpm | Read and write | |||
| Speed at Design Point [Hz] | Hz | Read and write | |||
| Pressure at Rated Speed | Read and write | ||||
| Flow at Design Point | Read and write | ||||
| Flow at Rated Speed | Read and write | ||||
| ON Time | Read and write | ||||
| ON Action | Read and write | ||||
| OFF Time | Read and write | ||||
| OFF Action | Read and write | ||||
| Occurrence | Read and write | ||||
| Timed Actions Mode | Read and write | ||||
| Timed Actions Reactivation | Read and write | ||||
| Maintenance Item | Read and write | ||||
| Maintenance Action | Read and write | ||||
| Maintenance Base | Read and write | ||||
| Maintenance Interval | Read and write | ||||
| Maintenance Date and Time | Read and write | ||||
| Reset Maintenance Word | Read and write | ||||
| Maintenance Text | Read and write | ||||
| Energy Log Resolution | Read and write | ||||
| Period Start | Read and write | ||||
| Energy Log | Read | ||||
| Reset Energy Log | Read and write | ||||
| Trend Variable | Read and write | ||||
| Continuous Bin Data | Read | ||||
| Timed Bin Data | Read | ||||
| Timed Period Start | Read and write | ||||
| Timed Period Stop | Read and write | ||||
| Minimum Bin Value | Read and write | ||||
| Reset Continuous Bin Data | Read and write | ||||
| Reset Timed Bin Data | Read and write | ||||
| Power Reference Factor | % | Read and write | |||
| Energy Cost | Read and write | ||||
| Investment | Read and write | ||||
| Energy Savings | kWh | Read | |||
| Cost Savings | Read | ||||
| CO2 Conversion Factor | Read and write | ||||
| CO2 Reduction | Read | ||||
| Emergency Mode Function | Read and write | ||||
| Emergency Mode Configuration | Read and write | ||||
| Emergency Mode Unit | Read and write | ||||
| Emergency Mode Min Reference | Read and write | ||||
| Emergency Mode Max Reference | Read and write | ||||
| Emergency Mode Preset Reference | % | Read and write | |||
| Emergency Mode Reference Source | Read and write | ||||
| Emergency Mode Feedback Source | Read and write | ||||
| Emergency Mode Alarm Handling | Read and write | ||||
| Drive Bypass Function | Read and write | ||||
| Drive Bypass Delay Time | s | Read and write | |||
| Emergency Mode Ramp Up Time | s | Read and write | |||
| Emergency Mode Ramp Down Time | s | Read and write | |||
| Timeout for Emergency Mode Test | min | Read and write | |||
| Emergency Mode Signal Operation | Read and write | ||||
| Cascade Controller | Read and write | ||||
| Motor Start | Read and write | ||||
| Pump Cycling | Read and write | ||||
| Fixed Lead Pump | Read and write | ||||
| Number of Pumps | Read and write | ||||
| Staging Bandwidth | Read and write | ||||
| Override Bandwidth | % | Read and write | |||
| Fixed Speed Bandwidth | % | Read and write | |||
| SBW Staging Delay | s | Read and write | |||
| SBW Destaging Delay | s | Read and write | |||
| OBW Time | s | Read and write | |||
| Destage at No-Flow | Read and write | ||||
| Stage Function | Read and write | ||||
| Stage Function Time | s | Read and write | |||
| Destage Function | Read and write | ||||
| Destage Function Time | s | Read and write | |||
| Ramp Down Delay | s | Read and write | |||
| Ramp Up Delay | s | Read and write | |||
| Staging Threshold | % | Read and write | |||
| Destaging Threshold | % | Read and write | |||
| Staging Speed [RPM] | rpm | Read | |||
| Staging Speed [Hz] | Hz | Read | |||
| Destaging Speed [RPM] | rpm | Read | |||
| Destaging Speed [Hz] | Hz | Read | |||
| Staging Principle | Read and write | ||||
| Lead Pump Alternation | Read and write | ||||
| Alternation Event | Read and write | ||||
| Alternation Time Interval | h | Read and write | |||
| Alternation Timer Value | Read | ||||
| Alternation Predefined Time | Read and write | ||||
| Alternation if Load <50% | Read and write | ||||
| Staging Mode at Alternation | Read and write | ||||
| Run Next Pump Delay | s | Read and write | |||
| Run on Mains Delay | s | Read and write | |||
| Cascade Status | Read | ||||
| Pump Status | Read and write | ||||
| Lead Pump | Read | ||||
| Relay Status | Read | ||||
| Pump ON Time | h | Read and write | |||
| Relay ON Time | h | Read | |||
| Reset Relay Counters | Read and write | ||||
| Inverse Interlock | Read | ||||
| Pump Interlock | Read and write | ||||
| Manual Alternation | Read and write | ||||
| Pipe Fill Enable | Read and write | ||||
| Pipe Fill Speed [RPM] | rpm | Read and write | |||
| Pipe Fill Speed [Hz] | Hz | Read and write | |||
| Pipe Fill Time | s | Read and write | |||
| Pipe Fill Rate | Read and write | ||||
| Filled Setpoint | Read and write | ||||
| No-flow Disable Timer | s | Read and write | |||
| Filled Setpoint Delay | s | Read and write | |||
| Derag Cycles | Read and write | ||||
| Derag at Start/Stop | Read and write | ||||
| Deragging Run Time | s | Read and write | |||
| Derag Speed [RPM] | rpm | Read and write | |||
| Derag Speed [Hz] | Hz | Read and write | |||
| Derag Off Delay | s | Read and write | |||
| Derag Counter | Read | ||||
| Reset Derag Counter | Read and write | ||||
| Rev. Derag Speed [RPM] | rpm | Read and write | |||
| Rev. Derag Speed [Hz] | Hz | Read and write | |||
| Derag Power [kW] | kW | Read | |||
| Derag Power [HP] | Read | ||||
| Derag Power Factor | % | Read and write | |||
| Derag Power Delay | s | Read and write | |||
| Low Speed [RPM] 29-24 | rpm | Read and write | |||
| Low Speed [Hz] 29-25 | Hz | Read and write | |||
| Low Speed Power [kW] 29-26 | kW | Read and write | |||
| Low Speed Power [HP] 29-27 | Read and write | ||||
| High Speed [RPM] 29-28 | rpm | Read and write | |||
| High Speed [Hz] 29-29 | Hz | Read and write | |||
| High Speed Power [kW] 29-30 | kW | Read and write | |||
| High Speed Power [HP] 29-31 | Read and write | ||||
| Derag On Ref Bandwidth | % | Read and write | |||
| Power Derag Limit | Read and write | ||||
| Consecutive Derag Interval | s | Read and write | |||
| Derag at Locked Rotor | Read and write | ||||
| Pre/Post Lube Function | Read and write | ||||
| Pre Lube Time | s | Read and write | |||
| Post Lube Time | s | Read and write | |||
| Validation Time | s | Read and write | |||
| Verification Time | s | Read and write | |||
| Signal Lost Verification Time | s | Read and write | |||
| Flow Confirmation Mode | Read and write | ||||
| Flow Meter Monitor | Read and write | ||||
| Flow Meter Source | Read and write | ||||
| Flow Meter Unit | Read and write | ||||
| Totalized Volume Unit | Read and write | ||||
| Actual Volume Unit | Read and write | ||||
| Totalized Volume | Read | ||||
| Actual Volume | Read | ||||
| Reset Totalized Volume | Read and write | ||||
| Reset Actual Volume | Read and write | ||||
| Flow | Read | ||||
| High Starting Torque Time [s] | s | Read and write | |||
| High Starting Torque Current [%] | % | Read and write | |||
| Locked Rotor Protection | Read and write | ||||
| Locked Rotor Detection Time [s] | s | Read and write | |||
| Locked Rotor Detection Speed Error [%] | % | Read and write | |||
| Heat Sink Fan Mode | Read and write | ||||
| Brake Resistor (ohm) 30-81 | Read and write | ||||
| Motor Frequency 30-85 | Hz | Read and write | |||
| Kin. Back-up UdcRef | V | Read and write | |||
| Kin. Back-up Integral Time | s | Read and write | |||
| Kin.Back-up Lead Filter Time | s | Read and write | |||
| Kin. Back-up Min Run Time | s | Read and write | |||
| Mains Loss Duration | s | Read and write | |||
| Kin.Back-up Start Off | V | Read and write | |||
| Individual Currents | Read and write | ||||
| Motor Current 40-37 | % | Read | |||
| Motor Torque | % | Read | |||
| Fault Log: Ext. Reference | % | Read | |||
| Alarm Log: Frequency | Hz | Read | |||
| Fault Log: Current | A | Read | |||
| Fault Log: Voltage | V | Read | |||
| Fault Log: DC Link Voltage | V | Read | |||
| Fault Log: Control Word | Read | ||||
| Fault Log: Status Word | Read | ||||
| Alarm Log: Torque | Nm | Read | |||
| Alarm Log: CBM Value | % | Read | |||
| Alarm Log: CBM Threshold | % | Read | |||
| Flux Sensorless Model Shift | Read and write | ||||
| Flux Sensorless Corr. Gain | Read and write | ||||
| Speed PID Anti Windup Gain | % | Read and write | |||
| Current PID Anti Windup Gain | Read and write | ||||
| Modulation Index | % | Read and write | |||
| Rotor Position Estimation Gain | % | Read and write | |||
| IPv6 Address Assignment | Read and write | ||||
| IPv6 Address | Read and write | ||||
| Prefix Length | Read and write | ||||
| Default Gateway | Read and write | ||||
| DHCPv6 Server | Read and write | ||||
| Lease Expires IPv6 | Read | ||||
| Name Servers IPv6 | Read and write | ||||
| IoT Profile | Read and write | ||||
| IoT Connection Info | Read and write | ||||
| UUID | Read and write | ||||
| 802.1X Port-Based Network Access Control | Read and write | ||||
| Protocol Status Word | Read and write | ||||
| Function 45-00 | Read and write | ||||
| Status 45-01 | Read | ||||
| Start Time | Read | ||||
| Stop Time | Read | ||||
| Readout Setting 45-09 | Read and write | ||||
| Alarm High Threshold | % | Read | |||
| Warning S2 High Threshold | % | Read |
Loading registers…
Send your device list
If a device is not in the library yet, we build the template for free as soon as we have the register data.
Use cases
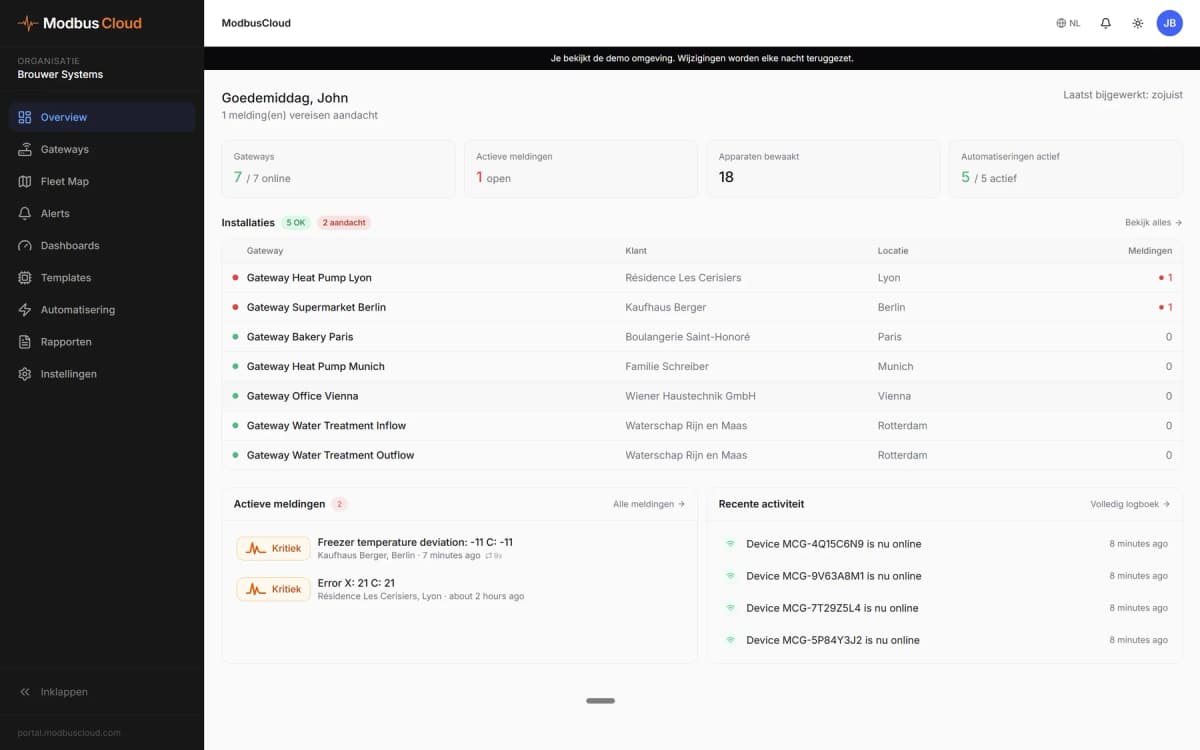
- Show frequency, motor current and power of every pump drive on one dashboard.
- Send an email when the alarm word is not equal to 0, so a tripped pump is noticed straight away.
- Keep a year of history of the feedback value and output frequency to see how a pressure station behaves.
- Change the closed-loop setpoint or the ramp time of a pump from the portal without visiting the site.
- Track running hours and the kWh counter per drive to plan maintenance and compare energy use.
Installation
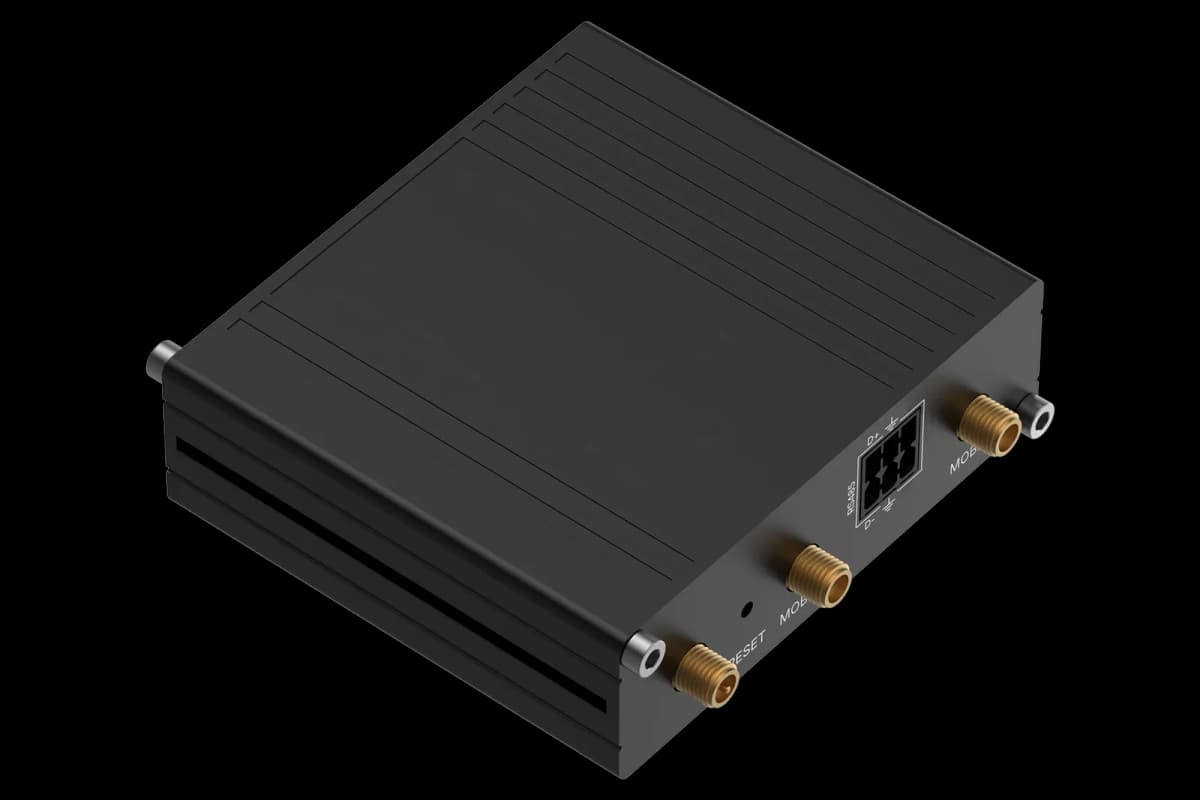
Connect terminals 68 (P, A) and 69 (N, B) of the drive to A and B of the ModbusCloud Gateway, with termination at both ends of the bus.
Set parameter 8-30 Protocol to Modbus RTU and check address (8-31), baud rate (8-32) and parity (8-33); the defaults are 1, 9600 baud and even parity, 1 stop bit.
In ModbusCloud, add a Modbus RTU device on the Gateway with the same settings and import this template.
Check that Frequency, Motor Current and DC Link Voltage show plausible values.
Things to watch for
The drive does not answer on Modbus. What should I check?
Parameter 8-30 must be set to Modbus RTU; the default protocol is FC. Compare address, baud rate and parity in 8-31 to 8-33 with the device settings in ModbusCloud, swap A and B if nothing comes back, and check the bus termination switch on the drive.
How do I find the register of a Danfoss parameter?
The register number is the parameter number times ten, so parameter 3-41 is register 3410 and address 3409 in the template. The parameter number is in the comment of each register, so you can match it with the drive display or the programming guide.
Some array parameters always show the first value.
For array parameters, such as the alarm log, the drive returns the element chosen in Parameter Array Index. Write the index you want there first, then read the array parameter.
Can I start the pump or change the speed from ModbusCloud?
Yes, with the Bus Control Word and Bus Reference registers or the control word coils, and parameters such as setpoints and ramps are writable too. Writing registers from ModbusCloud is switched on per gateway on request. Coil 65 decides whether a written parameter is also stored in EEPROM; write only what you need.


Want to see how it works?