
Danfoss VLT Midi Drive FC 280
Frequency converter for pumps, fans and machines: motor data, alarms, control and all parameters.
The Danfoss VLT Midi Drive FC 280 is a frequency converter that controls the speed of motors in pumps, fans, conveyors and machines. This Modbus RTU template reads frequency, current, power, speed, temperatures and alarms, and lets you start, stop and set the speed and every parameter of the drive from ModbusCloud.
- Protocol
- Modbus RTU
- Connection
- RS485, 9600 baud
- Registers
- 670, read and write
- Brand
- Danfoss
- Key readings
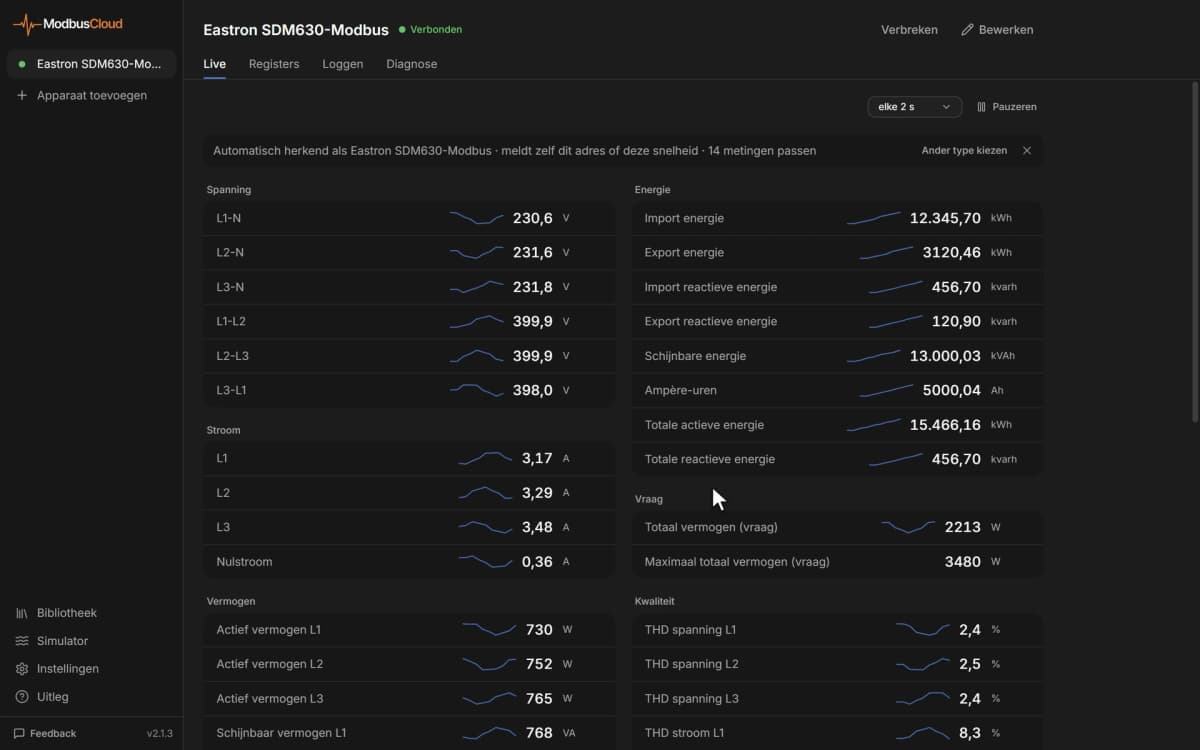
- Output frequency · Motor current · Motor voltage · Power · Speed · Heatsink temperature · Alarm and warning words · Running hours and kWh
- Available commands
- Start and stop · Speed reference · Reset · Ramps and speed limits · All parameters
- Compatible models
- VLT Midi Drive FC 280, all power sizes
- Last updated
Registers (670)
638 read, 547 write
| Name | Unit | Access | Address (Hidden until you enter your email) | Function (hidden) | Type (hidden) |
|---|---|---|---|---|---|
| Control Word (16-00) | Read | ||||
| Reference [Unit] (16-01) | Read | ||||
| Reference [%] (16-02) | % | Read | |||
| Status Word (16-03) | Read | ||||
| Main Actual Value [%] (16-05) | % | Read | |||
| Custom Readout (16-09) | Read | ||||
| Power [kW] (16-10) | kW | Read | |||
| Power [hp] (16-11) | Read | ||||
| Motor Voltage (16-12) | V | Read | |||
| Frequency (16-13) | Hz | Read | |||
| Motor current (16-14) | A | Read | |||
| Frequency [%] (16-15) | % | Read | |||
| Torque [Nm] (16-16) | Nm | Read | |||
| Speed [RPM] (16-17) | rpm | Read | |||
| Motor Thermal (16-18) | % | Read | |||
| Motor Angle (16-20) | Read | ||||
| Torque [%] (16-22) | % | Read | |||
| DC Link Voltage (16-30) | V | Read | |||
| Brake Energy /2 min (16-33) | kW | Read | |||
| Heatsink Temp. (16-34) | °C | Read | |||
| Inverter Thermal (16-35) | % | Read | |||
| Inv. Nom. Current (16-36) | A | Read | |||
| Inv. Max. Current (16-37) | A | Read | |||
| SL Controller State (16-38) | Read | ||||
| Control Card Temp. (16-39) | °C | Read | |||
| External Reference (16-50) | % | Read | |||
| Feedback[Unit] (16-52) | Read | ||||
| Digi Pot Reference (16-53) | Read | ||||
| Feedback [RPM] (16-57) | Read | ||||
| Digital Input (16-60) | Read | ||||
| Terminal 53 Setting (16-61) | Read | ||||
| Analog Input 53 (16-62) | Read | ||||
| Terminal 54 Setting (16-63) | Read | ||||
| Analog Input AI54 (16-64) | Read | ||||
| Analog Output 42 [mA] (16-65) | mA | Read | |||
| Digital Output (16-66) | Read | ||||
| Pulse Input 29[Hz] (16-67) | Hz | Read | |||
| Pulse Input 33 [Hz] (16-68) | Hz | Read | |||
| Pulse Output 27 [Hz] (16-69) | Hz | Read | |||
| Relay Output (16-71) | Read | ||||
| Counter A (16-72) | Read | ||||
| Counter B (16-73) | Read | ||||
| Prec. Stop Counter (16-74) | Read | ||||
| Fieldbus CTW 1 (16-80) | Read | ||||
| Fieldbus REF 1 (16-82) | Read | ||||
| Comm. Option STW (16-84) | Read | ||||
| FC Port CTW 1 (16-85) | Read | ||||
| FC Port REF 1 (16-86) | Read | ||||
| Alarm Word (16-90) | Read | ||||
| Alarm Word 2 (16-91) | Read | ||||
| Warning Word (16-92) | Read | ||||
| Warning Word 2 (16-93) | Read | ||||
| Ext. Status Word (16-94) | Read | ||||
| Ext. Status Word 2 (16-95) | Read | ||||
| Alarm Word 3 (16-97) | Read | ||||
| Warning Word 3 (16-98) | Read | ||||
| Operating hours (15-00) | Read | ||||
| Running Hours (15-01) | Read | ||||
| kWh Counter (15-02) | Read | ||||
| Power Up's (15-03) | Read | ||||
| Over Temp's (15-04) | Read | ||||
| Over Volt's (15-05) | Read | ||||
| Alarm Log: Error Code (15-30) | Read | ||||
| InternalFaultReason (15-31) | Read | ||||
| FC Type (15-40) | Read | ||||
| Power Section (15-41) | Read | ||||
| Voltage (15-42) | Read | ||||
| Software Version (15-43) | Read | ||||
| Ordered TypeCode (15-44) | Read | ||||
| Actual Typecode String (15-45) | Read | ||||
| Drive Ordering No (15-46) | Read | ||||
| LCP Id No (15-48) | Read | ||||
| SW ID Control Card (15-49) | Read | ||||
| SW ID Power Card (15-50) | Read | ||||
| Drive Serial Number (15-51) | Read | ||||
| OEM Information (15-52) | Read | ||||
| Power Card Serial Number (15-53) | Read | ||||
| File Version (15-57) | Read | ||||
| Filename (15-59) | Read | ||||
| Option Mounted (15-60) | Read | ||||
| Option SW Version (15-61) | Read | ||||
| Option in Slot A (15-70) | Read | ||||
| Slot A Option SW Version (15-71) | Read | ||||
| Defined Parameters (15-92) | Read | ||||
| Application Type (15-97) | Read | ||||
| Drive Identification (15-98) | Read | ||||
| Parameter Metadata (15-99) | Read | ||||
| Readout: Edit Set-ups / Channel (0-14) | Read | ||||
| Actual Value (9-07) | Read | ||||
| Actual Baud Rate (9-63) | Read | ||||
| Readout Transmit Error Counter (10-05) | Read | ||||
| Readout Receive Error Counter (10-06) | Read | ||||
| Actual Position (34-50) | Read | ||||
| Status Control Ready | Read | ||||
| Status Drive Ready | Read | ||||
| Status Safety Closed | Read | ||||
| Status Alarm | Read | ||||
| Status Warning | Read | ||||
| Status At Reference | Read | ||||
| Status Auto Mode | Read | ||||
| Status In Frequency Range | Read | ||||
| Status Running | Read | ||||
| Status Voltage Warning | Read | ||||
| Status Current Limit | Read | ||||
| Status Thermal Warning | Read | ||||
| Output Frequency Bit 0 | Read | ||||
| Output Frequency Bit 1 | Read | ||||
| Output Frequency Bit 2 | Read | ||||
| Output Frequency Bit 3 | Read | ||||
| Output Frequency Bit 4 | Read | ||||
| Output Frequency Bit 5 | Read | ||||
| Output Frequency Bit 6 | Read | ||||
| Output Frequency Bit 7 | Read | ||||
| Output Frequency Bit 8 | Read | ||||
| Output Frequency Bit 9 | Read | ||||
| Output Frequency Bit 10 | Read | ||||
| Output Frequency Bit 11 | Read | ||||
| Output Frequency Bit 12 | Read | ||||
| Output Frequency Bit 13 | Read | ||||
| Output Frequency Bit 14 | Read | ||||
| Output Frequency Bit 15 | Read | ||||
| Last Fault Code | Read | ||||
| Last Error Register | Read | ||||
| Index Pointer | Read and write | ||||
| Control Word Preset Reference LSB | Write | ||||
| Control Word Preset Reference MSB | Write | ||||
| Control Word No DC Brake | Write | ||||
| Control Word No Coast Stop | Write | ||||
| Control Word No Quick Stop | Write | ||||
| Control Word No Freeze Frequency | Write | ||||
| Control Word Start | Write | ||||
| Control Word Reset | Write | ||||
| Control Word Jog | Write | ||||
| Control Word Ramp 2 | Write | ||||
| Control Word Data Valid | Write | ||||
| Control Word Relay 1 On | Write | ||||
| Control Word Relay 2 On | Write | ||||
| Control Word Set-up LSB | Write | ||||
| Control Word Reversing | Write | ||||
| Speed Reference Bit 0 | Write | ||||
| Speed Reference Bit 1 | Write | ||||
| Speed Reference Bit 2 | Write | ||||
| Speed Reference Bit 3 | Write | ||||
| Speed Reference Bit 4 | Write | ||||
| Speed Reference Bit 5 | Write | ||||
| Speed Reference Bit 6 | Write | ||||
| Speed Reference Bit 7 | Write | ||||
| Speed Reference Bit 8 | Write | ||||
| Speed Reference Bit 9 | Write | ||||
| Speed Reference Bit 10 | Write | ||||
| Speed Reference Bit 11 | Write | ||||
| Speed Reference Bit 12 | Write | ||||
| Speed Reference Bit 13 | Write | ||||
| Speed Reference Bit 14 | Write | ||||
| Speed Reference Bit 15 | Write | ||||
| Parameter Write to EEPROM | Write | ||||
| Reset kWh Counter (15-06) | Read and write | ||||
| Reset Running Hours Counter (15-07) | Read and write | ||||
| Language (0-01) | Read and write | ||||
| Regional Settings (0-03) | Read and write | ||||
| Operating State at Power-up (0-04) | Read and write | ||||
| GridType (0-06) | Read and write | ||||
| Auto DC Braking (0-07) | Read and write | ||||
| Active Set-up (0-10) | Read and write | ||||
| Programming Set-up (0-11) | Read and write | ||||
| Link Setups (0-12) | Read and write | ||||
| Application Selection (0-16) | Read and write | ||||
| Display Line 1.1 Small (0-20) | Read and write | ||||
| Display Line 1.2 Small (0-21) | Read and write | ||||
| Display Line 1.3 Small (0-22) | Read and write | ||||
| Display Line 2 Large (0-23) | Read and write | ||||
| Display Line 3 Large (0-24) | Read and write | ||||
| Custom Readout Unit (0-30) | Read and write | ||||
| Custom Readout Min Value (0-31) | Read and write | ||||
| Custom Readout Max Value (0-32) | Read and write | ||||
| Display Text 1 (0-37) | Read and write | ||||
| Display Text 2 (0-38) | Read and write | ||||
| Display Text 3 (0-39) | Read and write | ||||
| [Hand on] Key on LCP (0-40) | Read and write | ||||
| [Auto on] Key on LCP (0-42) | Read and write | ||||
| [Off/Reset] Key on LCP (0-44) | Read and write | ||||
| LCP Copy (0-50) | Read and write | ||||
| Set-up Copy (0-51) | Read and write | ||||
| Main Menu Password (0-60) | Read and write | ||||
| Configuration Mode (1-00) | Read and write | ||||
| Motor Control Principle (1-01) | Read and write | ||||
| Torque Characteristics (1-03) | Read and write | ||||
| Clockwise Direction (1-06) | Read and write | ||||
| Motor Control Bandwidth (1-08) | Read and write | ||||
| Motor Construction (1-10) | Read and write | ||||
| Damping Gain (1-14) | % | Read and write | |||
| Low Speed Filter Time Const. (1-15) | Read and write | ||||
| High Speed Filter Time Const. (1-16) | Read and write | ||||
| Voltage filter time const. (1-17) | Read and write | ||||
| Motor Power (1-20) | Read and write | ||||
| Motor Voltage (1-22) | Read and write | ||||
| Motor Frequency (1-23) | Read and write | ||||
| Motor Current (1-24) | Read and write | ||||
| Motor Nominal Speed (1-25) | Read and write | ||||
| Motor Cont. Rated Torque (1-26) | Read and write | ||||
| Automatic Motor Adaption (AMA) (1-29) | Read and write | ||||
| Stator Resistance (Rs) (1-30) | Read and write | ||||
| Rotor Resistance (Rr) (1-31) | Read and write | ||||
| Stator Leakage Reactance (X1) (1-33) | Read and write | ||||
| Main Reactance (Xh) (1-35) | Read and write | ||||
| d-axis Inductance (Ld) (1-37) | Read and write | ||||
| q-axis Inductance (Lq) (1-38) | Read and write | ||||
| Motor Poles (1-39) | Read and write | ||||
| Back EMF at 1000 RPM (1-40) | Read and write | ||||
| Motor Cable Length (1-42) | m | Read and write | |||
| Motor Cable Length Feet (1-43) | Read and write | ||||
| d-axis Inductance Sat. (LdSat) (1-44) | Read and write | ||||
| q-axis Inductance Sat. (LqSat) (1-45) | Read and write | ||||
| Position Detection Gain (1-46) | % | Read and write | |||
| Current at Min Inductance for d- axis (1-48) | % | Read and write | |||
| Current at Min Inductance for q- axis (1-49) | % | Read and write | |||
| Motor Magnetisation at Zero Speed (1-50) | % | Read and write | |||
| Min Speed Normal Magnetising [Hz] (1-52) | Hz | Read and write | |||
| U/f Characteristic - U (1-55) | Read and write | ||||
| U/f Characteristic - F (1-56) | Read and write | ||||
| Low Speed Load Compensation (1-60) | % | Read and write | |||
| High Speed Load Compensation (1-61) | % | Read and write | |||
| Slip Compensation (1-62) | Read and write | ||||
| Slip Compensation Time Constant (1-63) | s | Read and write | |||
| Resonance Dampening (1-64) | % | Read and write | |||
| Resonance Dampening Time Constant (1-65) | s | Read and write | |||
| Min. Current at Low Speed (1-66) | % | Read and write | |||
| PM Start Mode (1-70) | Read and write | ||||
| Start Delay (1-71) | s | Read and write | |||
| Start Function (1-72) | Read and write | ||||
| Flying Start (1-73) | Read and write | ||||
| Start Speed [Hz] (1-75) | Hz | Read and write | |||
| Start Current (1-76) | Read and write | ||||
| Compressor Start Max Speed [Hz] (1-78) | Hz | Read and write | |||
| Compressor Start Max Time to Trip (1-79) | s | Read and write | |||
| Function at Stop (1-80) | Read and write | ||||
| Min Speed for Function at Stop [Hz] (1-82) | Hz | Read and write | |||
| Precise Stop Function (1-83) | Read and write | ||||
| Precise Stop Counter Value (1-84) | Read and write | ||||
| Precise Stop Speed Compensation Delay (1-85) | s | Read and write | |||
| AC Brake Gain (1-88) | Read and write | ||||
| Motor Thermal Protection (1-90) | Read and write | ||||
| Thermistor Source (1-93) | Read and write | ||||
| DC Hold/Motor Preheat Current (2-00) | % | Read and write | |||
| DC Brake Current (2-01) | % | Read and write | |||
| DC Braking Time (2-02) | s | Read and write | |||
| DC Brake Cut In Speed (2-04) | Hz | Read and write | |||
| Parking Current (2-06) | % | Read and write | |||
| Parking Time (2-07) | s | Read and write | |||
| Brake Function (2-10) | Read and write | ||||
| Brake Resistor (ohm) (2-11) | Read and write | ||||
| Brake Power Limit (kW) (2-12) | Read and write | ||||
| Brake voltage reduce (2-14) | V | Read and write | |||
| AC Brake, Max current (2-16) | % | Read and write | |||
| Over-voltage Control (2-17) | Read and write | ||||
| Over-voltage Gain (2-19) | % | Read and write | |||
| Release Brake Current (2-20) | A | Read and write | |||
| Activate Brake Speed [Hz] (2-22) | Hz | Read and write | |||
| Activate Brake Delay (2-23) | s | Read and write | |||
| Reference Range (3-00) | Read and write | ||||
| Reference/Feedback Unit (3-01) | Read and write | ||||
| Minimum Reference (3-02) | Read and write | ||||
| Maximum Reference (3-03) | Read and write | ||||
| Reference Function (3-04) | Read and write | ||||
| Preset Reference (3-10) | % | Read and write | |||
| Jog Speed [Hz] (3-11) | Hz | Read and write | |||
| Catch up/slow Down Value (3-12) | % | Read and write | |||
| Preset Relative Reference (3-14) | % | Read and write | |||
| Reference 1 Source (3-15) | Read and write | ||||
| Reference 2 Source (3-16) | Read and write | ||||
| Reference 3 Source (3-17) | Read and write | ||||
| Relative Scaling Reference Resource (3-18) | Read and write | ||||
| Ramp Down w/ dir. Change (3-31) | Read and write | ||||
| Ramp 1 Type (3-40) | Read and write | ||||
| Ramp 1 Ramp Up Time (3-41) | Read and write | ||||
| Ramp 1 Ramp Down Time (3-42) | Read and write | ||||
| Ramp 2 Type (3-50) | Read and write | ||||
| Ramp 2 Ramp Up Time (3-51) | Read and write | ||||
| Ramp 2 Ramp Down Time (3-52) | Read and write | ||||
| Ramp 3 Type (3-60) | Read and write | ||||
| Ramp 3 Ramp up Time (3-61) | Read and write | ||||
| Ramp 3 Ramp down Time (3-62) | Read and write | ||||
| Ramp 4 Type (3-70) | Read and write | ||||
| Ramp 4 Ramp up Time (3-71) | Read and write | ||||
| Ramp 4 Ramp Down Time (3-72) | Read and write | ||||
| Jog Ramp Time (3-80) | Read and write | ||||
| Quick Stop Ramp Time (3-81) | Read and write | ||||
| Step Size (3-90) | % | Read and write | |||
| Power Restore (3-92) | Read and write | ||||
| Maximum Limit (3-93) | % | Read and write | |||
| Minimum Limit (3-94) | % | Read and write | |||
| Ramp Delay (3-95) | s | Read and write | |||
| Maximum Limit Switch Reference (3-96) | % | Read and write | |||
| Motor Speed Direction (4-10) | Read and write | ||||
| Motor Speed Low Limit [Hz] (4-12) | Hz | Read and write | |||
| Motor Speed High Limit [Hz] (4-14) | Hz | Read and write | |||
| Torque Limit Motor Mode (4-16) | Read and write | ||||
| Torque Limit Generator Mode (4-17) | % | Read and write | |||
| Current Limit (4-18) | Read and write | ||||
| Max Output Frequency (4-19) | Read and write | ||||
| Torque Limit Factor Source (4-20) | Read and write | ||||
| Speed Limit Factor Source (4-21) | Read and write | ||||
| Break Away Boost (4-22) | Read and write | ||||
| Motor Feedback Loss Function (4-30) | Read and write | ||||
| Motor Feedback Speed Error (4-31) | Hz | Read and write | |||
| Motor Feedback Loss Timeout (4-32) | s | Read and write | |||
| Warning Freq. Low (4-40) | Read and write | ||||
| Warning Freq. High (4-41) | Read and write | ||||
| Adjustable Temperature Warning (4-42) | Read and write | ||||
| Warning Current Low (4-50) | A | Read and write | |||
| Warning Current High (4-51) | Read and write | ||||
| Warning Reference Low (4-54) | Read and write | ||||
| Warning Reference High (4-55) | Read and write | ||||
| Warning Feedback Low (4-56) | Read and write | ||||
| Warning Feedback High (4-57) | Read and write | ||||
| Missing Motor Phase Function (4-58) | Read and write | ||||
| Bypass Speed From [Hz] (4-61) | Hz | Read and write | |||
| Bypass Speed To [Hz] (4-63) | Hz | Read and write | |||
| Digital I/O Mode (5-00) | Read and write | ||||
| Terminal 27 Mode (5-01) | Read and write | ||||
| Terminal 18 Digital Input (5-10) | Read and write | ||||
| Terminal 19 Digital Input (5-11) | Read and write | ||||
| Terminal 27 Digital Input (5-12) | Read and write | ||||
| Terminal 29 Digital Input (5-13) | Read and write | ||||
| Terminal 32 Digital Input (5-14) | Read and write | ||||
| Terminal 33 Digital Input (5-15) | Read and write | ||||
| Terminal 37/38 Safe Torque Off (5-19) | Read and write | ||||
| Terminal 27 Digital Output (5-30) | Read and write | ||||
| On Delay, Digital Output (5-34) | s | Read and write | |||
| Off Delay, Digital Output (5-35) | s | Read and write | |||
| Function Relay (5-40) | Read and write | ||||
| On Delay, Relay (5-41) | s | Read and write | |||
| Off Delay, Relay (5-42) | s | Read and write | |||
| Term. 29 Low Frequency (5-50) | Hz | Read and write | |||
| Term. 29 High Frequency (5-51) | Hz | Read and write | |||
| Term. 29 Low Ref./Feedb. Value (5-52) | Read and write | ||||
| Term. 29 High Ref./Feedb. Value (5-53) | Read and write | ||||
| Term. 33 Low Frequency (5-55) | Hz | Read and write | |||
| Term. 33 High Frequency (5-56) | Hz | Read and write | |||
| Term. 33 Low Ref./Feedb. Value (5-57) | Read and write | ||||
| Term. 33 High Ref./Feedb. Value (5-58) | Read and write | ||||
| Terminal 27 Pulse Output Variable (5-60) | Read and write | ||||
| Pulse Output Max Freq 27 (5-62) | Hz | Read and write | |||
| Term 32/33 Pulses Per Revolution (5-70) | Read and write | ||||
| Term 32/33 Encoder Direction (5-71) | Read and write | ||||
| Digital & Relay Bus Control (5-90) | Read and write | ||||
| Pulse Out 27 Bus Control (5-93) | % | Read and write | |||
| Pulse Out 27 Timeout Preset (5-94) | % | Read and write | |||
| Live Zero Timeout Time (6-00) | s | Read and write | |||
| Live Zero Timeout Function (6-01) | Read and write | ||||
| Terminal 53 Low Voltage (6-10) | V | Read and write | |||
| Terminal 53 High Voltage (6-11) | V | Read and write | |||
| Terminal 53 Low Ref./Feedb. Value (6-14) | Read and write | ||||
| Terminal 53 High Ref./Feedb. Value (6-15) | Read and write | ||||
| Terminal 53 Filter Time Constant (6-16) | s | Read and write | |||
| Terminal 53 Digital Input (6-18) | Read and write | ||||
| Terminal 53 mode (6-19) | Read and write | ||||
| Terminal 54 Low Voltage (6-20) | V | Read and write | |||
| Terminal 54 High Voltage (6-21) | V | Read and write | |||
| Terminal 54 Low Current (6-22) | Read and write | ||||
| Terminal 54 High Current (6-23) | Read and write | ||||
| Terminal 54 Low Ref./Feedb. Value (6-24) | Read and write | ||||
| Terminal 54 High Ref./Feedb. Value (6-25) | Read and write | ||||
| Terminal 54 Filter Time Constant (6-26) | s | Read and write | |||
| Terminal 54 mode (6-29) | Read and write | ||||
| Terminal 42 Mode (6-90) | Read and write | ||||
| Terminal 42 Analog Output (6-91) | Read and write | ||||
| Terminal 42 Digital Output (6-92) | Read and write | ||||
| Terminal 42 Output Min Scale (6-93) | % | Read and write | |||
| Terminal 42 Output Max Scale (6-94) | % | Read and write | |||
| Terminal 42 Output Bus Control (6-96) | Read and write | ||||
| Speed PID Feedback Source (7-00) | Read and write | ||||
| Speed PID Proportional Gain (7-02) | Read and write | ||||
| Speed PID Integral Time (7-03) | s | Read and write | |||
| Speed PID Differentiation Time (7-04) | s | Read and write | |||
| Speed PID Diff. Gain Limit (7-05) | Read and write | ||||
| Speed PID Lowpass Filter Time (7-06) | s | Read and write | |||
| Speed PID Feedback Gear Ratio (7-07) | Read and write | ||||
| Speed PID Feed Forward Factor (7-08) | % | Read and write | |||
| Torque PID Proportional Gain (7-12) | % | Read and write | |||
| Torque PID Integration Time (7-13) | s | Read and write | |||
| Process CL Feedback 1 Resource (7-20) | Read and write | ||||
| Process CL Feedback 2 Resource (7-22) | Read and write | ||||
| Process PID Normal/ Inverse Control (7-30) | Read and write | ||||
| Process PID Anti Windup (7-31) | Read and write | ||||
| Process PID Start Speed (7-32) | Read and write | ||||
| Process PID Proportional Gain (7-33) | Read and write | ||||
| Process PID Integral Time (7-34) | s | Read and write | |||
| Process PID Differentiation Time (7-35) | s | Read and write | |||
| Process PID Diff. Gain Limit (7-36) | Read and write | ||||
| Process PID Feed Forward Factor (7-38) | % | Read and write | |||
| On Reference Bandwidth (7-39) | % | Read and write | |||
| Process PID I-part Reset (7-40) | Read and write | ||||
| Process PID Output Neg. Clamp (7-41) | % | Read and write | |||
| Process PID Output Pos. Clamp (7-42) | % | Read and write | |||
| Process PID Gain Scale at Min. Ref. (7-43) | % | Read and write | |||
| Process PID Gain Scale at Max. Ref. (7-44) | % | Read and write | |||
| Process PID Feed Fwd Resource (7-45) | Read and write | ||||
| Process PID Feed Fwd Normal/ Inv. Ctrl. (7-46) | Read and write | ||||
| PCD Feed Forward (7-48) | Read and write | ||||
| Process PID Output Normal/ Inv. Ctrl. (7-49) | Read and write | ||||
| Process PID Extended PID (7-50) | Read and write | ||||
| Process PID Feed Fwd Gain (7-51) | Read and write | ||||
| Process PID Feed Fwd Ramp up (7-52) | s | Read and write | |||
| Process PID Feed Fwd Ramp down (7-53) | s | Read and write | |||
| Process PID Ref. Filter Time (7-56) | s | Read and write | |||
| Process PID Fb. Filter Time (7-57) | s | Read and write | |||
| Feedback 1 Conversion (7-60) | Read and write | ||||
| Feedback 2 Conversion (7-62) | Read and write | ||||
| Option A warning control (8-00) | Read and write | ||||
| Control Site (8-01) | Read and write | ||||
| Control Source (8-02) | Read and write | ||||
| Control Timeout Time (8-03) | s | Read and write | |||
| Control Timeout Function (8-04) | Read and write | ||||
| Diagnosis Trigger (8-07) | Read and write | ||||
| Control Word Profile (8-10) | Read and write | ||||
| Configurable Status Word STW (8-13) | Read and write | ||||
| Configurable Control Word CTW (8-14) | Read and write | ||||
| Product Code (8-19) | Read and write | ||||
| Protocol (8-30) | Read and write | ||||
| Address (8-31) | Read and write | ||||
| Baud Rate (8-32) | Read and write | ||||
| Parity / Stop Bits (8-33) | Read and write | ||||
| Minimum Response Delay (8-35) | s | Read and write | |||
| Maximum Response Delay (8-36) | Read and write | ||||
| PCD Write Configuration (8-42) | Read and write | ||||
| PCD Read Configuration (8-43) | Read and write | ||||
| Coasting Select (8-50) | Read and write | ||||
| Quick Stop Select (8-51) | Read and write | ||||
| DC Brake Select (8-52) | Read and write | ||||
| Start Select (8-53) | Read and write | ||||
| Reversing Select (8-54) | Read and write | ||||
| Set-up Select (8-55) | Read and write | ||||
| Preset Reference Select (8-56) | Read and write | ||||
| Profidrive OFF2 Select (8-57) | Read and write | ||||
| Profidrive OFF3 Select (8-58) | Read and write | ||||
| Protocol Firmware version (8-79) | Read and write | ||||
| Bus Message Count (8-80) | Read and write | ||||
| Bus Error Count (8-81) | Read and write | ||||
| Slave Messages Rcvd (8-82) | Read and write | ||||
| Slave Error Count (8-83) | Read and write | ||||
| Slave Messages Sent (8-84) | Read and write | ||||
| Slave Timeout Errors (8-85) | Read and write | ||||
| Reset FC port Diagnostics (8-88) | Read and write | ||||
| Bus Jog 1 Speed (8-90) | Read and write | ||||
| Bus Jog 2 Speed (8-91) | Read and write | ||||
| Setpoint (9-00) | Read and write | ||||
| PCD Write Configuration (9-15) | Read and write | ||||
| PCD Read Configuration (9-16) | Read and write | ||||
| Node Address (9-18) | Read and write | ||||
| Drive Unit System Number (9-19) | Read and write | ||||
| Telegram Selection (9-22) | Read and write | ||||
| Parameters for Signals (9-23) | Read and write | ||||
| Parameter Edit (9-27) | Read and write | ||||
| Process Control (9-28) | Read and write | ||||
| Fault Message Counter (9-44) | Read and write | ||||
| Fault Code (9-45) | Read and write | ||||
| Fault Number (9-47) | Read and write | ||||
| Fault Situation Counter (9-52) | Read and write | ||||
| Profibus Warning Word (9-53) | Read and write | ||||
| Device Identification (9-64) | Read and write | ||||
| Profile Number (9-65) | Read and write | ||||
| Control Word 1 (9-67) | Read and write | ||||
| Status Word 1 (9-68) | Read and write | ||||
| Edit Set-up (9-70) | Read and write | ||||
| Profibus Save Data Values (9-71) | Read and write | ||||
| ProfibusDriveReset (9-72) | Read and write | ||||
| DO Identification (9-75) | Read and write | ||||
| Defined Parameters (1) (9-80) | Read and write | ||||
| Defined Parameters (2) (9-81) | Read and write | ||||
| Defined Parameters (3) (9-82) | Read and write | ||||
| Defined Parameters (4) (9-83) | Read and write | ||||
| Defined Parameters (5) (9-84) | Read and write | ||||
| Defined Parameters (6) (9-85) | Read and write | ||||
| Changed Parameters (1) (9-90) | Read and write | ||||
| Changed Parameters (2) (9-91) | Read and write | ||||
| Changed Parameters (3) (9-92) | Read and write | ||||
| Changed Parameters (4) (9-93) | Read and write | ||||
| Changed Parameters (5) (9-94) | Read and write | ||||
| Profibus Revision Counter (9-99) | Read and write | ||||
| Baud Rate Select (10-01) | Read and write | ||||
| Node ID (10-02) | Read and write | ||||
| Store Data Values (10-31) | Read and write | ||||
| Store Always (10-33) | Read and write | ||||
| IP Address Assignment (12-00) | Read and write | ||||
| IP Address (12-01) | Read and write | ||||
| Subnet Mask (12-02) | Read and write | ||||
| Default Gateway (12-03) | Read and write | ||||
| DHCP Server (12-04) | Read and write | ||||
| Lease Expires (12-05) | Read and write | ||||
| Name Servers (12-06) | Read and write | ||||
| Domain Name (12-07) | Read and write | ||||
| Host Name (12-08) | Read and write | ||||
| Physical Address (12-09) | Read and write | ||||
| Link Status (12-10) | Read and write | ||||
| Link Duration (12-11) | Read and write | ||||
| Auto Negotiation (12-12) | Read and write | ||||
| Link Speed (12-13) | Read and write | ||||
| Link Duplex (12-14) | Read and write | ||||
| Process Data Config Write Size (12-23) | Read and write | ||||
| Process Data Config Read Size (12-24) | Read and write | ||||
| Node ID (12-60) | Read and write | ||||
| SDO Timeout (12-62) | Read and write | ||||
| Basic Ethernet Timeout (12-63) | Read and write | ||||
| Threshold (12-66) | Read and write | ||||
| Threshold Counters (12-67) | Read and write | ||||
| Cumulative Counters (12-68) | Read and write | ||||
| Ethernet PowerLink Status (12-69) | Read and write | ||||
| FTP Server (12-80) | Read and write | ||||
| HTTP Server (12-81) | Read and write | ||||
| SMTP Service (12-82) | Read and write | ||||
| Transparent Socket Channel Port (12-89) | Read and write | ||||
| Cable Diagnostic (12-90) | Read and write | ||||
| Auto Cross Over (12-91) | Read and write | ||||
| IGMP Snooping (12-92) | Read and write | ||||
| Cable Error Length (12-93) | Read and write | ||||
| Broadcast Storm Protection (12-94) | % | Read and write | |||
| Inactivity timeout (12-95) | Read and write | ||||
| Port Config (12-96) | Read and write | ||||
| QoS Priority (12-97) | Read and write | ||||
| Interface Counters (12-98) | Read and write | ||||
| Media Counters (12-99) | Read and write | ||||
| SL Controller Mode (13-00) | Read and write | ||||
| Start Event (13-01) | Read and write | ||||
| Stop Event (13-02) | Read and write | ||||
| Reset SLC (13-03) | Read and write | ||||
| Comparator Operand (13-10) | Read and write | ||||
| Comparator Operator (13-11) | Read and write | ||||
| Comparator Value (13-12) | Read and write | ||||
| SL Controller Timer (13-20) | s | Read and write | |||
| Logic Rule Boolean 1 (13-40) | Read and write | ||||
| Logic Rule Operator 1 (13-41) | Read and write | ||||
| Logic Rule Boolean 2 (13-42) | Read and write | ||||
| Logic Rule Operator 2 (13-43) | Read and write | ||||
| Logic Rule Boolean 3 (13-44) | Read and write | ||||
| SL Controller Event (13-51) | Read and write | ||||
| SL Controller Action (13-52) | Read and write | ||||
| Switching Frequency (14-01) | Read and write | ||||
| Overmodulation (14-03) | Read and write | ||||
| Dead Time Compensation Level (14-07) | Read and write | ||||
| Damping Gain Factor (14-08) | Read and write | ||||
| Dead Time Bias Current Level (14-09) | Read and write | ||||
| Mains Failure (14-10) | Read and write | ||||
| Mains Voltage at Mains Fault (14-11) | Read and write | ||||
| Function at Mains Imbalance (14-12) | Read and write | ||||
| Kin. Backup Trip Recovery Level (14-15) | Read and write | ||||
| Fast Mains Phase Loss Level (14-17) | % | Read and write | |||
| Fast Mains Phase Loss Min Power (14-18) | % | Read and write | |||
| Counter Clear Time (14-19) | Read and write | ||||
| Reset Mode (14-20) | Read and write | ||||
| Automatic Restart Time (14-21) | s | Read and write | |||
| Operation Mode (14-22) | Read and write | ||||
| Trip Delay at Current Limit (14-24) | s | Read and write | |||
| Trip Delay at Torque Limit (14-25) | s | Read and write | |||
| Action At Inverter Fault (14-27) | Read and write | ||||
| Production Settings (14-28) | Read and write | ||||
| Service Code (14-29) | Read and write | ||||
| Current Lim Ctrl, Proportional Gain (14-30) | % | Read and write | |||
| Current Lim Ctrl, Integration Time (14-31) | s | Read and write | |||
| Current Lim Ctrl, Filter Time (14-32) | s | Read and write | |||
| VT Level (14-40) | % | Read and write | |||
| AEO Minimum Magnetisation (14-41) | % | Read and write | |||
| d-axis current optimization for IPM (14-44) | % | Read and write | |||
| RFI Filter (14-50) | Read and write | ||||
| DC-Link Voltage Compensation (14-51) | Read and write | ||||
| Fan Control (14-52) | Read and write | ||||
| Output Filter (14-55) | Read and write | ||||
| Function at Inverter Overload (14-61) | Read and write | ||||
| Min Switch Frequency (14-63) | Read and write | ||||
| Dead Time Compensation Zero Current Level (14-64) | Read and write | ||||
| Speed Derate Dead Time Compensation (14-65) | Read and write | ||||
| Compatibility Selections (14-70) | Read and write | ||||
| Option Data Storage (14-88) | Read and write | ||||
| Option Detection (14-89) | Read and write | ||||
| Fault Level (14-90) | Read and write | ||||
| Memory Module Warning Reason (18-51) | Read and write | ||||
| Memory Module ID (18-52) | Read and write | ||||
| Process PID Error (18-90) | % | Read and write | |||
| Process PID Output (18-91) | % | Read and write | |||
| Process PID Clamped Output (18-92) | % | Read and write | |||
| Process PID Gain Scaled Output (18-93) | % | Read and write | |||
| Extended PID Enable (21-09) | Read and write | ||||
| Ext. 1 Minimum Reference (21-11) | Read and write | ||||
| Ext. 1 Maximum Reference (21-12) | Read and write | ||||
| Ext. 1 Reference Source (21-13) | Read and write | ||||
| Ext. 1 Feedback Source (21-14) | Read and write | ||||
| Ext. 1 Setpoint (21-15) | Read and write | ||||
| Ext. 1 Reference [Unit] (21-17) | Read and write | ||||
| Ext. 1 Feedback [Unit] (21-18) | Read and write | ||||
| Ext. 1 Output [%] (21-19) | % | Read and write | |||
| Ext. 1 Normal/Inverse Control (21-20) | Read and write | ||||
| Ext. 1 Proportional Gain (21-21) | Read and write | ||||
| Ext. 1 Integral Time (21-22) | s | Read and write | |||
| Ext. 1 Differentation Time (21-23) | s | Read and write | |||
| Ext. 1 Dif. Gain Limit (21-24) | Read and write | ||||
| Minimum Run Time (22-40) | s | Read and write | |||
| Minimum Sleep Time (22-41) | s | Read and write | |||
| Wake-Up Speed [Hz] (22-43) | Hz | Read and write | |||
| Wake-Up Ref./FB Diff (22-44) | % | Read and write | |||
| Setpoint Boost (22-45) | % | Read and write | |||
| Maximum Boost Time (22-46) | s | Read and write | |||
| Sleep Speed [Hz] (22-47) | Hz | Read and write | |||
| Broken Belt Function (22-60) | Read and write | ||||
| Broken Belt Torque (22-61) | % | Read and write | |||
| Broken Belt Delay (22-62) | s | Read and write | |||
| High Starting Torque Time [s] (30-20) | s | Read and write | |||
| High Starting Torque Current [%] (30-21) | % | Read and write | |||
| Locked Rotor Detection (30-22) | Read and write | ||||
| Locked Rotor Detection Time [s] (30-23) | s | Read and write | |||
| Memory Module Function (31-40) | Read and write | ||||
| MM Information (31-41) | Read and write | ||||
| Configure Memory Module Access (31-42) | Read and write | ||||
| Erase_MM (31-43) | Read and write | ||||
| Time Limit Function (31-47) | Read and write | ||||
| Time Limit Remaining Time (31-48) | Read and write | ||||
| User Unit Denominator (32-11) | Read and write | ||||
| User Unit Numerator (32-12) | Read and write | ||||
| Max. Tolerated Position Error (32-67) | Read and write | ||||
| Maximum Allowed Velocity (32-80) | Read and write | ||||
| Motion Ctrl Quick Stop Ramp (32-81) | s | Read and write | |||
| Homing Mode (33-00) | Read and write | ||||
| Home Offset (33-01) | Read and write | ||||
| Home Ramp Time (33-02) | s | Read and write | |||
| Homing Velocity (33-03) | Read and write | ||||
| Homing Behaviour (33-04) | Read and write | ||||
| Negative Software Limit (33-41) | Read and write | ||||
| Positive Software Limit (33-42) | Read and write | ||||
| Negative Software Limit Active (33-43) | Read and write | ||||
| Positive Software Limit Active (33-44) | Read and write | ||||
| Target Position Window (33-47) | Read and write | ||||
| PCD 1 Write For Application (34-01) | Read and write | ||||
| PCD 2 Write For Application (34-02) | Read and write | ||||
| PCD 3 Write For Application (34-03) | Read and write | ||||
| PCD 4 Write For Application (34-04) | Read and write | ||||
| PCD 5 Write For Application (34-05) | Read and write | ||||
| PCD 6 Write For Application (34-06) | Read and write | ||||
| PCD 7 Write For Application (34-07) | Read and write | ||||
| PCD 8 Write For Application (34-08) | Read and write | ||||
| PCD 9 Write For Application (34-09) | Read and write | ||||
| PCD 10 Write For Application (34-10) | Read and write | ||||
| PCD 1 Read For Application (34-21) | Read and write | ||||
| PCD 2 Read For Application (34-22) | Read and write | ||||
| PCD 3 Read For Application (34-23) | Read and write | ||||
| PCD 4 Read For Application (34-24) | Read and write | ||||
| PCD 5 Read For Application (34-25) | Read and write | ||||
| PCD 6 Read For Application (34-26) | Read and write | ||||
| PCD 7 Read For Application (34-27) | Read and write | ||||
| PCD 8 Read For Application (34-28) | Read and write | ||||
| PCD 9 Read For Application (34-29) | Read and write | ||||
| PCD 10 Read For Application (34-30) | Read and write | ||||
| Track Error (34-56) | Read and write | ||||
| Application Mode (37-00) | Read and write | ||||
| Pos. Feedback Source (37-01) | Read and write | ||||
| Pos. Target (37-02) | Read and write | ||||
| Pos. Type (37-03) | Read and write | ||||
| Pos. Velocity (37-04) | Read and write | ||||
| Pos. Ramp Up Time (37-05) | s | Read and write | |||
| Pos. Ramp Down Time (37-06) | s | Read and write | |||
| Pos. Auto Brake Ctrl (37-07) | Read and write | ||||
| Pos. Hold Delay (37-08) | s | Read and write | |||
| Pos. Coast Delay (37-09) | s | Read and write | |||
| Pos. Brake Delay (37-10) | s | Read and write | |||
| Pos. Brake Wear Limit (37-11) | Read and write | ||||
| Pos. PID Anti Windup (37-12) | Read and write | ||||
| Pos. PID Output Clamp (37-13) | Read and write | ||||
| Pos. Ctrl. Source (37-14) | Read and write | ||||
| Pos. Direction Block (37-15) | Read and write | ||||
| Pos. Ctrl Fault Behaviour (37-17) | Read and write | ||||
| Pos. Ctrl Fault Reason (37-18) | Read and write | ||||
| Pos. New Index (37-19) | Read and write |
Loading registers…
Send your device list
If a device is not in the library yet, we build the template for free as soon as we have the register data.
Use cases
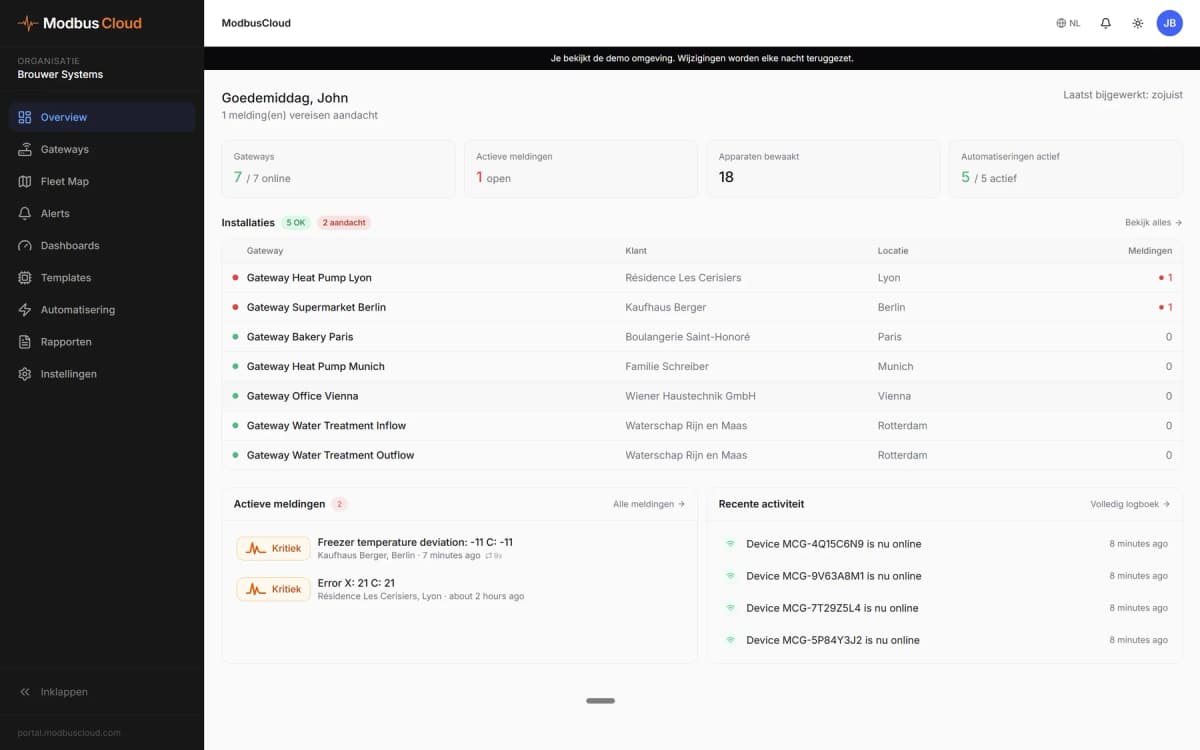
- Show frequency, motor current, power and heatsink temperature of a pump or fan drive on a dashboard.
- Get an email when the alarm word changes or the drive reports a warning, so you can act before a trip stops the process.
- Track running hours and kWh per drive to plan maintenance and see energy use per machine.
- Change ramps, speed limits or a preset reference remotely once writing is switched on, without a visit to the panel.
Installation
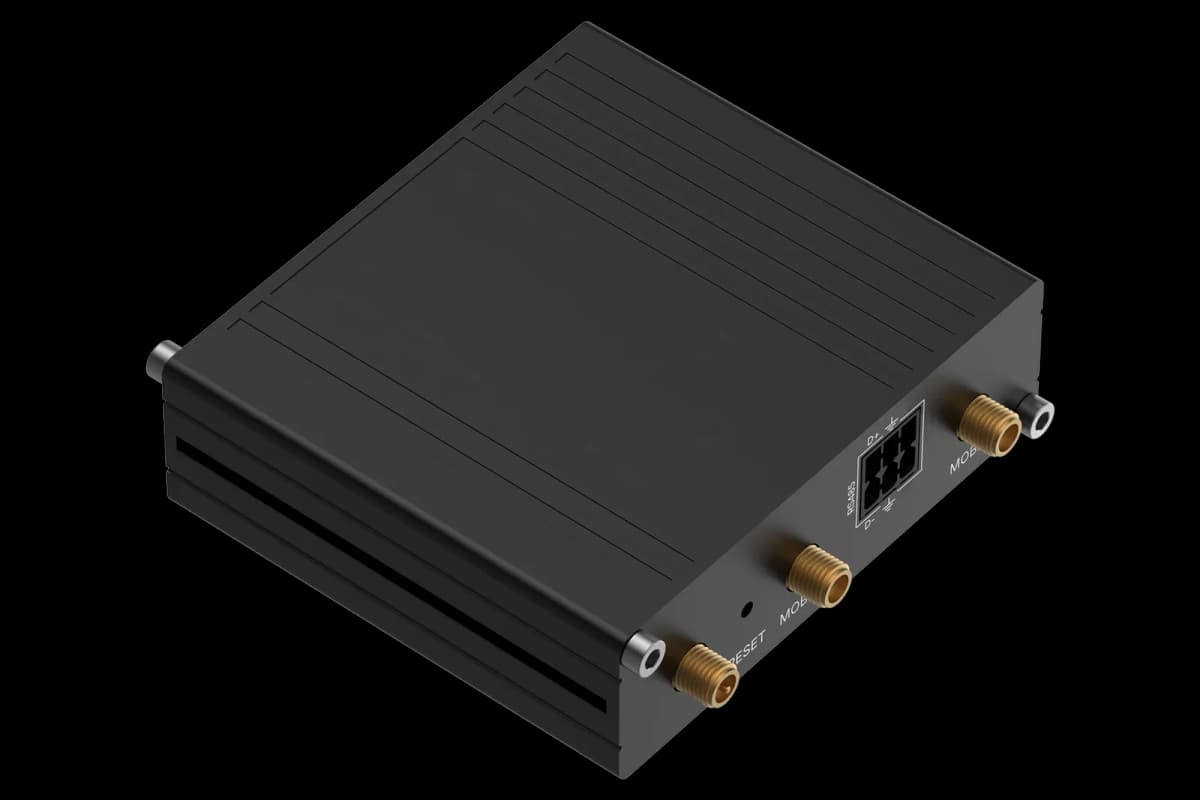
Connect terminals 68 (+), 69 (-) and 61 of the FC 280 to the RS485 port of the ModbusCloud Gateway and terminate the bus at both ends.
Set 8-30 Protocol to Modbus RTU, give the drive an address in 8-31 and set baud rate and parity in 8-32 and 8-33.
For control over Modbus, set the control site and coasting and quick stop selection in group 8-0 and 8-5 to allow the bus.
In ModbusCloud, add a Modbus device (RTU) with the same address and settings, import this template and check that frequency and current arrive.
Things to watch for
Parameters read back a value 10 or 100 times too large.
Parameters are sent as whole numbers with a conversion index. The template sets the matching scale for each parameter; when you add a parameter yourself, use 0.1 for index -1 and 0.01 for index -2.
Reading a 32-bit parameter gives an error.
32-bit parameters such as 16-13 Frequency take 2 registers and must be read together. Each parameter has its own block of registers, so do not read across into the next parameter.
Writes to an array parameter land in the wrong element.
Array parameters such as 3-10 Preset Reference use the index pointer register. Write the wanted index there first, then read or write the parameter.
Can I control the motor from ModbusCloud?
Yes, once writing registers is switched on for your gateway. The control word coils start and stop the drive and the reference coils set the speed. Settings written over Modbus go to RAM unless the EEPROM coil is set, and a remote start can surprise people near the machine, so agree on it on site first.


Want to see how it works?