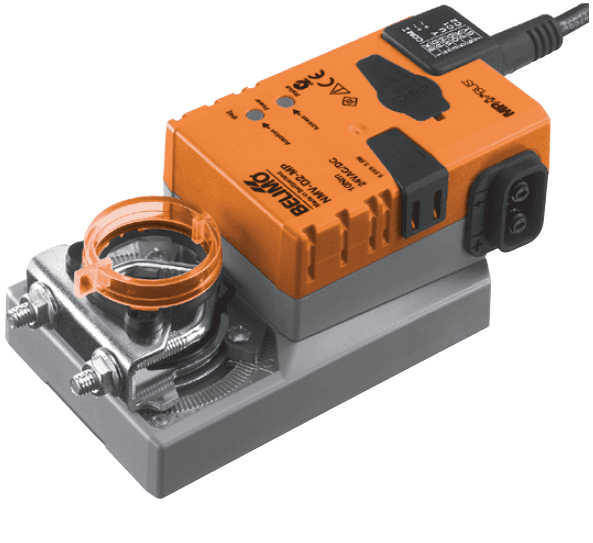
Belimo VAV-Compact Modbus RTU
Provides integrated VAV/CAV pressure sensing, airflow control, and damper actuation via Modbus RTU.
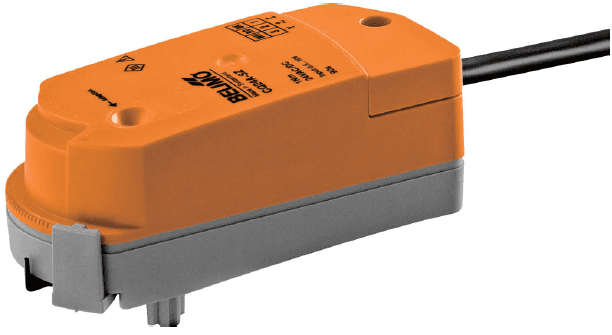
The Belimo VAV-Compact (MV-D3-MOD) is an all-in-one pressure sensor, digital VAV controller, and damper actuator communicating via Modbus RTU at 38400 baud. This template reads airflow, actuator position, and sensor values while providing setpoint and override controls for pressure-independent VAV and CAV systems.
- Protocol
- Modbus RTU
- Connection
- RS485, 38400 baud
- Registers
- 27, read and write
- Brand
- Belimo
- Key readings
- Relative Position · Absolute Position · Relative Volumetric Flow · Absolute Volumetric Flow · Sensor 1 Value · Malfunction and Service Information
- Available commands
- Setpoint · Override Control · Minimum/Maximum Limits · Bus Fail Position
- Compatible models
- MV-D3-MOD
- Last updated
Registers (27)
16 read, 11 write
| Name | Unit | Access | Address (Hidden until you enter your email) | Function (hidden) | Type (hidden) |
|---|---|---|---|---|---|
| Actuator Type | Read | ||||
| Relative Position | % | Read | |||
| Absolute Position | °C | Read | |||
| Sensor 1 Value | Read | ||||
| Setpoint Analog | % | Read | |||
| Series Number 1st Part | Read | ||||
| Series Number 2nd Part | Read | ||||
| Series Number 4th Part | Read | ||||
| Firmware Version | Read | ||||
| Malfunction and Service Information | Read | ||||
| Relative volumetric flow | % | Read | |||
| Absolute volumetric flow in m3 per hour | m³/h | Read | |||
| Absolute volumetric flow in selected units | m³/h | Read | |||
| Nominal volumetric flow in m3 per hour | m³/h | Read | |||
| Nominal volumetric flow in selected unit | m³/h | Read | |||
| Control mode | Read | ||||
| Setpoint | % | Write | |||
| Override Control | Write | ||||
| Command | Write | ||||
| Bus Termination | Write | ||||
| Minimum | % | Write | |||
| Maximum | % | Write | |||
| Sensor 1 Type | Write | ||||
| Bus Fail Position | Write | ||||
| Timeout for Bus Watchdog in s | s | Write | |||
| Setpoint Source | Write | ||||
| Unit selection flow | Write |
Loading registers…
Send your device list
If a device is not in the library yet, we build the template for free as soon as we have the register data.
Use cases
- Monitor absolute volumetric airflow and damper position per zone on a live cloud dashboard.
- Adjust VAV setpoints remotely during commissioning without returning to site.
- Create an alert when a malfunction or service flag is raised by the VAV-Compact.
- Log relative and absolute airflow data over time to verify ventilation performance against design specifications.
- Set minimum and maximum airflow limits centrally for multiple zones in a building.
- Configure bus fail positions remotely to ensure safe damper behavior during communication loss.
Installation
Wire the Modbus RTU A and B lines from the Belimo MV-D3-MOD to the RS-485 port on your ModbusCloud Gateway, observing correct polarity.
Set the Modbus slave address on the VAV-Compact to a unique value on the bus and confirm the baud rate is 38400.
If the device is at the end of the RS-485 daisy chain, enable bus termination via register 99.
Configure the bus watchdog timeout in register 109 to define the failsafe delay in seconds.
In the ModbusCloud portal, select the Belimo VAV-Compact template and assign the correct slave address to begin reading data.
Verify that airflow, position, and sensor values appear on the dashboard before closing the installation.
Things to watch for
Why am I not getting any response from the VAV-Compact?
Confirm that the baud rate on both the gateway and the device is set to 38400. Also verify A/B wiring polarity and check that the Modbus slave address matches the address configured in ModbusCloud.
Absolute volumetric flow shows an incorrect value. What could be wrong?
Absolute volumetric flow (address 10) and nominal volumetric flow (address 112) are uint32 values spanning two registers. Make sure the template is reading both registers and that the byte/word order matches the device configuration.
The damper moves to an unexpected position when communication drops. How do I fix this?
The bus fail position register determines where the damper moves on communication loss. Adjust this register to your desired failsafe position. Also set the watchdog timeout in register 109 to an appropriate number of seconds.
Do I need to enable bus termination on the device?
Enable termination via register 99 only if the VAV-Compact is the last device on the RS-485 bus segment. Incorrect termination can cause communication errors across the entire bus.
Want to see how it works?